ISISComputingGroup / ISISComputingGroup/IBEX
IOC Motor: Alarm should be shown when motor does not move to setpoint
- 主要言語
- 言語のデータがありません
- スター
- 6
- フォーク
- 2
- 平均マージ
- 16時間 40分
- マージ済み PR(30日)
- 2
説明
As a MARI instrument scientist, I would like to know when a move has not succeeded so I can take remedial action.
### Acceptance Criteria
1. An appropriate error condition has been identified
1. An appropriate way of raising an alarm has been identified
1. When a motor had failed to move to a given postion an alarm is signalled.
1. Make sure the behaviour for max retries of 0 is documented
### Notes
1. Possible implementations:
1. if the motor has done all its retries, i.e. retry count > max
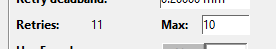
1. Compare the setpoint - current poistion to the retry deadband. Careful because the MTR0101.VAL gets set tot he RBV value on stop/fault so this can not be the setpoint used
1. I would suggest the appropriate place for the alarm is a Major alarm on the motor readback value `MOT:MTR0X0X.RBV`
1. This should be committed back to the community if it turns out this is a change in the motor record itself
コントリビューションガイド
このリポジトリのコントリビューションガイドは索引されていません
調査の方向性
この issue にはファイル、テスト、エントリーポイントが記載されていません。まず motor IOC と motor-record のアラームの所有箇所を特定し、次にエラー条件、アラーム機構、max-retries-of-zero の動作を明らかにしてください。モーターの移動に失敗したときに motor readback でアラームが発生し、リトライ動作が文書化されていれば完了です。
索引モデルが issue の本文から書いたものです。
評価
- 領域
- embedded-iot
- issue の種類
- 機能追加
- 難易度
- 5/5
- 見積もり時間
- 1週間以上
- 活発さ
- 停滞
- 明瞭さ
- 説明が足りない
- 初心者へのやさしさ
- 30/100