ISISComputingGroup / ISISComputingGroup/IBEX
IOC Motor: Alarm should be shown when motor does not move to setpoint
- Lingua principale
- Nessun dato sulla lingua
- Stelle
- 6
- Fork
- 2
- Merge medio
- 16h 40m
- PR unite (30g)
- 2
Descrizione
As a MARI instrument scientist, I would like to know when a move has not succeeded so I can take remedial action.
### Acceptance Criteria
1. An appropriate error condition has been identified
1. An appropriate way of raising an alarm has been identified
1. When a motor had failed to move to a given postion an alarm is signalled.
1. Make sure the behaviour for max retries of 0 is documented
### Notes
1. Possible implementations:
1. if the motor has done all its retries, i.e. retry count > max
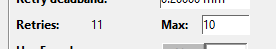
1. Compare the setpoint - current poistion to the retry deadband. Careful because the MTR0101.VAL gets set tot he RBV value on stop/fault so this can not be the setpoint used
1. I would suggest the appropriate place for the alarm is a Major alarm on the motor readback value `MOT:MTR0X0X.RBV`
1. This should be committed back to the community if it turns out this is a change in the motor record itself
Guida per i contributori
Nessuna guida per i contributori indicizzata per questo repository
Valutazione
Questa issue non è ancora stata valutata.