ISISComputingGroup / ISISComputingGroup/IBEX
IOC Motor: Alarm should be shown when motor does not move to setpoint
- Lenguaje dominante
- Sin datos de lenguaje
- Estrellas
- 6
- Forks
- 2
- Merge medio
- 16 h 40 min
- PR fusionados (30 d)
- 2
Descripción
As a MARI instrument scientist, I would like to know when a move has not succeeded so I can take remedial action.
### Acceptance Criteria
1. An appropriate error condition has been identified
1. An appropriate way of raising an alarm has been identified
1. When a motor had failed to move to a given postion an alarm is signalled.
1. Make sure the behaviour for max retries of 0 is documented
### Notes
1. Possible implementations:
1. if the motor has done all its retries, i.e. retry count > max
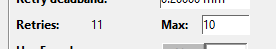
1. Compare the setpoint - current poistion to the retry deadband. Careful because the MTR0101.VAL gets set tot he RBV value on stop/fault so this can not be the setpoint used
1. I would suggest the appropriate place for the alarm is a Major alarm on the motor readback value `MOT:MTR0X0X.RBV`
1. This should be committed back to the community if it turns out this is a change in the motor record itself
Guía de contribución
No hay ninguna guía de contribución indexada para este repositorio
Línea de trabajo
El issue no menciona archivos, pruebas ni puntos de entrada. Empieza determinando la responsabilidad de las alarmas de motor IOC y motor-record, y después resuelve la condición de error, el mecanismo de alarma y el comportamiento de max-retries-of-zero. Se considera terminado cuando un movimiento fallido activa una alarma en el motor readback y el comportamiento de reintento está documentado.
Escrito por el modelo de indexación a partir del texto del issue.
Evaluación
- Área
- embedded-iot
- Tipo de issue
- Nueva funcionalidad
- Dificultad
- 5/5
- Tiempo estimado
- Más de una semana
- Estado de actividad
- Estancado
- Claridad
- Necesita aclaración
- Aptitud para principiantes
- 30/100