ISISComputingGroup / ISISComputingGroup/IBEX
IOC Motor: Alarm should be shown when motor does not move to setpoint
- Vorherrschende Sprache
- Keine Sprachdaten
- Sterne
- 6
- Forks
- 2
- Ø Merge
- 16 Std. 40 Min.
- Gemergte PRs (30 T.)
- 2
Beschreibung
As a MARI instrument scientist, I would like to know when a move has not succeeded so I can take remedial action.
### Acceptance Criteria
1. An appropriate error condition has been identified
1. An appropriate way of raising an alarm has been identified
1. When a motor had failed to move to a given postion an alarm is signalled.
1. Make sure the behaviour for max retries of 0 is documented
### Notes
1. Possible implementations:
1. if the motor has done all its retries, i.e. retry count > max
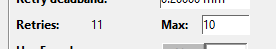
1. Compare the setpoint - current poistion to the retry deadband. Careful because the MTR0101.VAL gets set tot he RBV value on stop/fault so this can not be the setpoint used
1. I would suggest the appropriate place for the alarm is a Major alarm on the motor readback value `MOT:MTR0X0X.RBV`
1. This should be committed back to the community if it turns out this is a change in the motor record itself
Beitragsleitfaden
Für dieses Repository ist kein Beitragsleitfaden indexiert
Rechercherichtung
The issue names no files, tests, or entry points. Start by determining the motor IOC and motor-record alarm ownership, then resolve the error condition, alarm mechanism, and max-retries-of-zero behavior. Done means a failed move signals an alarm on the motor readback and the retry behavior is documented.
Vom Indexierungsmodell aus dem Issue-Text verfasst.
Bewertung
- Bereich
- embedded-iot
- Issue-Typ
- Feature
- Schwierigkeit
- 5/5
- Geschätzter Aufwand
- Über eine Woche
- Aktivitätsstatus
- Veraltet
- Klarheit
- Muss geklärt werden
- Anfängerfreundlichkeit
- 30/100