CodingTrain / CodingTrain/Suggestion-Box
Ray Casting in Box2D Processing
- Ngôn ngữ chính
- Không có dữ liệu ngôn ngữ
- Star
- 570
- Fork
- 85
- Chỉ số merge pull request
- Không có pull request nào được merge trong 30 ngày
Mô tả
I've been scouring the internet for ages looking for a good example/tutorial on how to use the rayCastCallback() function in Box2DProcessing. The only ones that I have found are for C++ or jBox2d and thus I don't know what libraries to import or proper syntax. If you could make a tutorial on ray casting in Box2dProcessing I would really appreciate it.
Just some context (if you care to know):
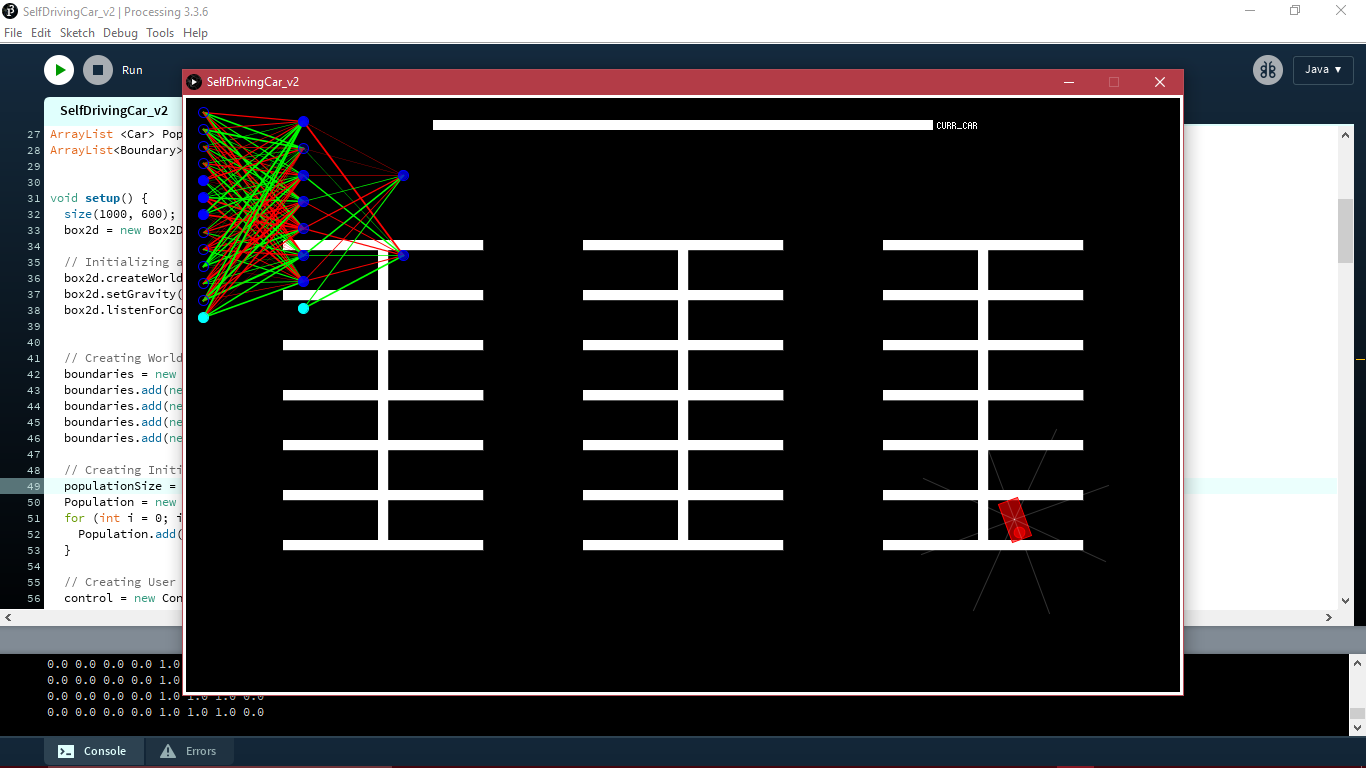
I was really inspired but you tutorials on Neural Networks and Genetic algorithms that I decided attempt to make a Neuroevolution program to create cars that can avoid other cars and park themselves. I have been able to implement the neural network, and the math needed to support it. Each car has a neural network that takes in inputs (from sensors) and produces output (steering and throttle). A car receives this input from its 12 sensors: 8 collision aversion sensors tell the car if it is about to collide with something, and 4 other senses tell it how far it is from its parking spot. The 8 collisions aversion (C.A.) sensors have fd.isSensor = true. I took into account that sensors collide with their own car (since they originate from it's center). The issue is that sometimes the collision listener beginContact/endContact does not trigger when it overlaps with a Boundary and only triggers in response to a Car when it collides with the center of the car. Sometimes, the sensors collisions do not register until the car collides with something. This defeats the purpose of the sensor. If you wouldn't mind revisiting collision listening in Box2D I would really appreciate you help so I can get on to the fun part-the genetic algorithm. Thank you!
Hướng dẫn đóng góp
Chưa lập chỉ mục được hướng dẫn đóng góp cho kho mã nguồn này
Hướng nghiên cứu
Bắt đầu với API rayCastCallback() của Box2DProcessing và hành vi của sensor và collision-listener được mô tả trong issue. Một đóng góp hoàn chỉnh cần cung cấp một tutorial trình bày các import và cú pháp cần thiết cho ray casting, đồng thời giải thích hành vi chồng lấn sensor đã được báo cáo với các boundary và car.
Do mô hình lập chỉ mục viết ra từ nội dung của issue.
Đánh giá
- Lĩnh vực
- documentation, game-dev
- Loại issue
- Tài liệu
- Độ khó
- 4/5
- Thời gian dự kiến
- 3-5 ngày
- Mức độ hoạt động
- Đình trệ
- Độ rõ ràng
- Khá rõ ràng
- Mức phù hợp với người mới
- 35/100