How to predict 3d box with PointPillars when point_cloud_range contains x<0
- Dominant language
- Python
- Stars
- 2.3k
- Forks
- 365
- Avg merge
- 4h 6m
- Merged PRs (30d)
- 1
Description
### Checklist
- [X] I have searched for [similar issues](https://github.com/isl-org/Open3D-ML/issues).
- [X] I have tested with the [latest development wheel](http://www.open3d.org/docs/latest/getting_started.html#development-version-pip).
- [X] I have checked the [release documentation](http://www.open3d.org/docs/release/) and the [latest documentation](http://www.open3d.org/docs/latest/) (for `master` branch).
### My Question
when i modify `pointpillars_kitti.yml` to the below. the result is error.
```yaml
model:
name: PointPillars
ckpt_path: # path/to/your/checkpoint
batcher: "ignore"
point_cloud_range: [-69.12, -39.68, -3, 69.12, 39.68, 1]
...
head:
in_channels: 384
feat_channels: 384
nms_pre: 100
score_thr: 0.1
ranges: [
[-70.4, -39.68, -0.6, 70.4, 39.68, -0.6],
[-70.4, -39.68, -0.6, 70.4, 39.68, -0.6],
[-70.4, -39.68, -1.78, 70.4, 39.68, -1.78]
]
...
augment:
PointShuffle: True
ObjectRangeFilter:
point_cloud_range: [-69.12, -39.68, -3, 69.12, 39.68, 1]
...
```
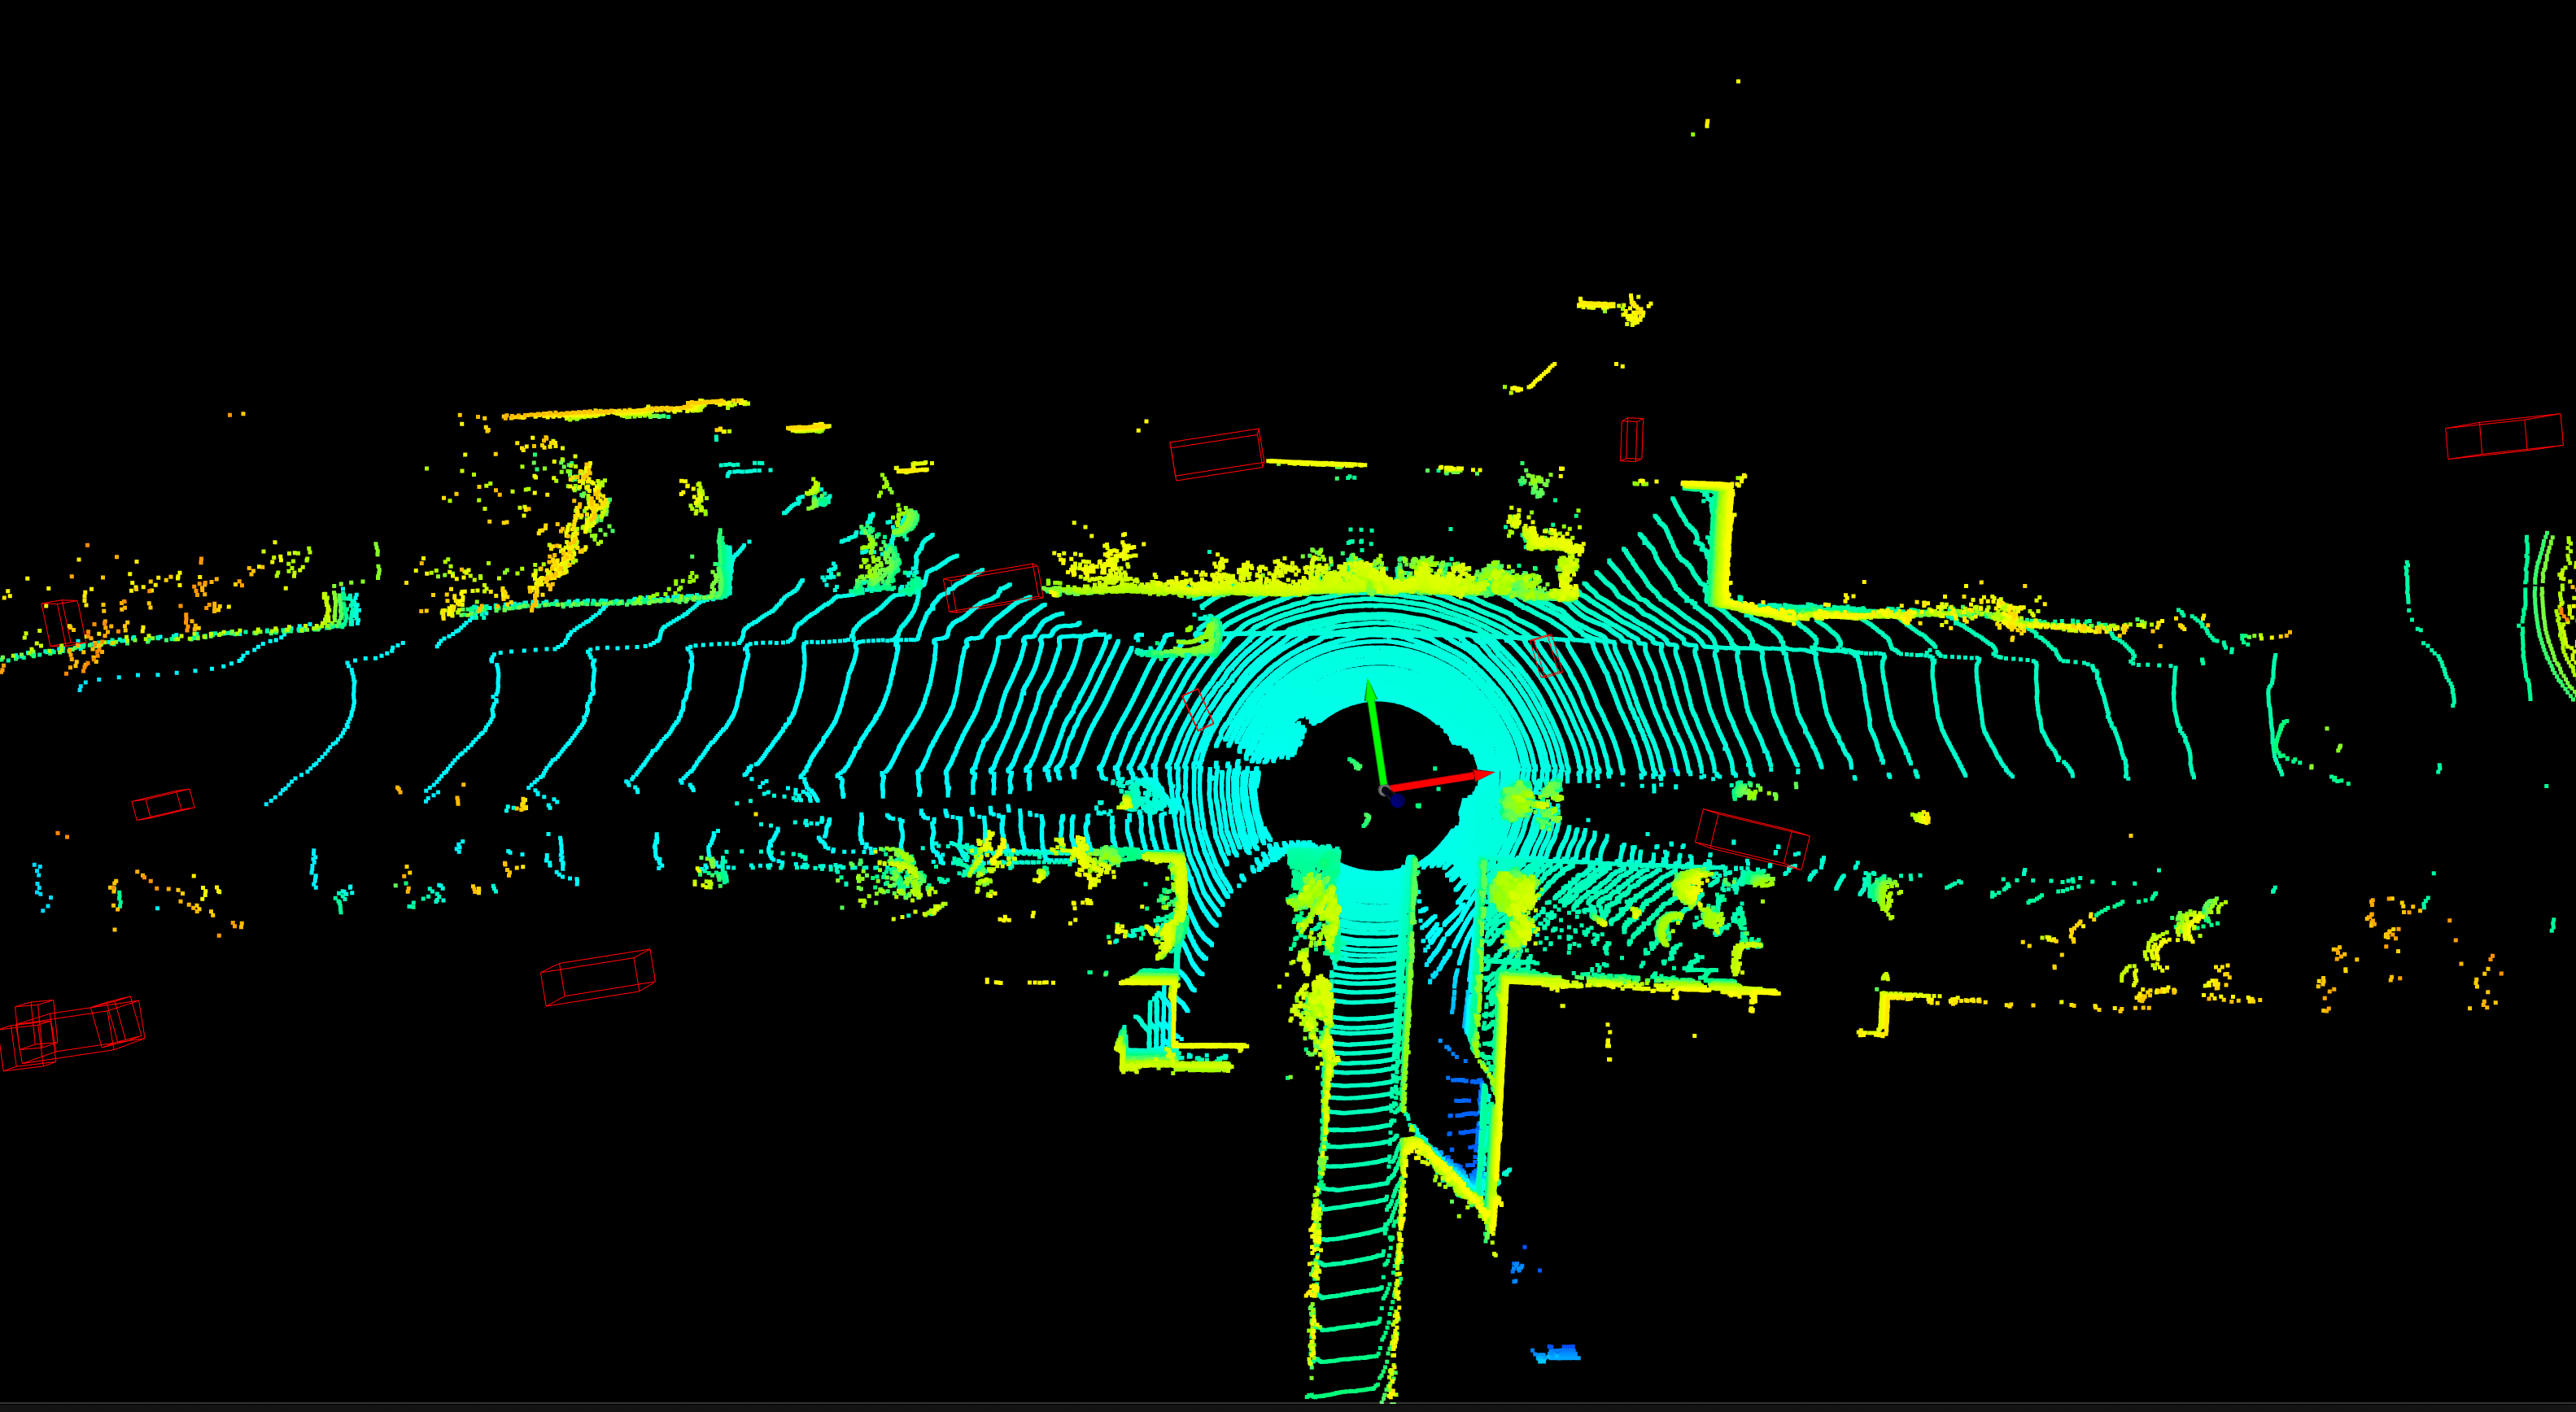
result like this:
Contributor guide
No contributing guide indexed for this repository
Assessment
This issue has not been assessed yet.