EricssonResearch / EricssonResearch/arms
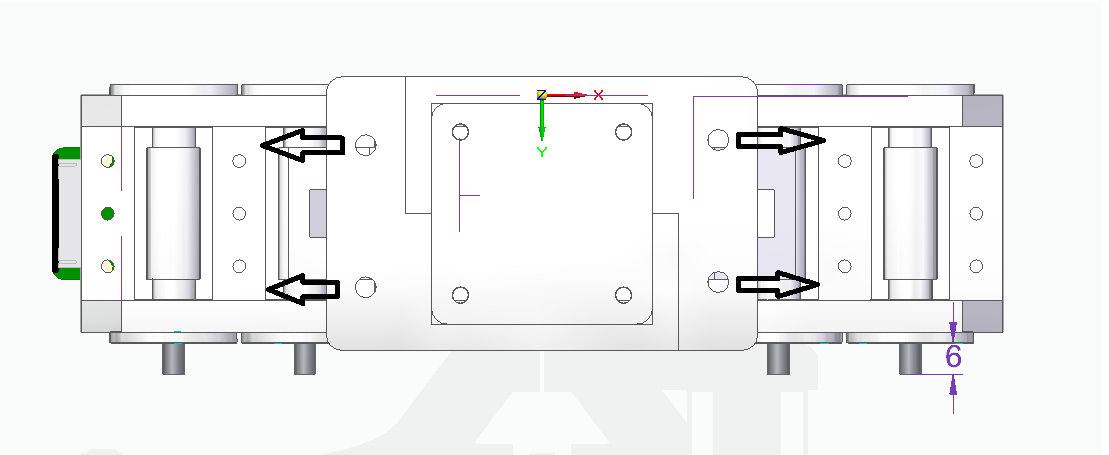
Modify claw house and gripper/sensor interface OR find a good way of assembling the current solution
- Dominant language
- Python
- Stars
- 6
- Forks
- 2
- PR merge metrics
- No merged PRs in 30d
Description
Claw house & gripper/sensor interface has to be modified by moving the screw holes (connecting it to the gripper/sensor interface plate) even further out from the center so that screws can actually be fastened correctly when joining them, see attached figure. This may just be a few millimeters (5 or so?). TAKE A LOOK AT THE ACTUAL FASTENING AND MAKE OWN JUDGEMENT OF HOW TO MAKE FASTENING EASIER.
Also the glued on contraption preventing the gripper from rotating needs to be remade since it fell off. Do not glue it on again.
ANOTHER OPTION: Create proper screws and find the proper tooling to make the current assembly viable when on the arm.
Contributor guide
No contributing guide indexed for this repository
Assessment
This issue has not been assessed yet.