AIS-Bonn / AIS-Bonn/object_detection_in_laser_range_data
Could not wait for transform from velodyne to world
- Linguagem predominante
- C++
- Estrelas
- 15
- Forks
- 0
- Métricas de merge de PRs
- Nenhum PR com merge em 30d
Descrição
Hi, I am sorry to bother you again.
Now I can add distance field and publish it successfully. But I face some new problems:
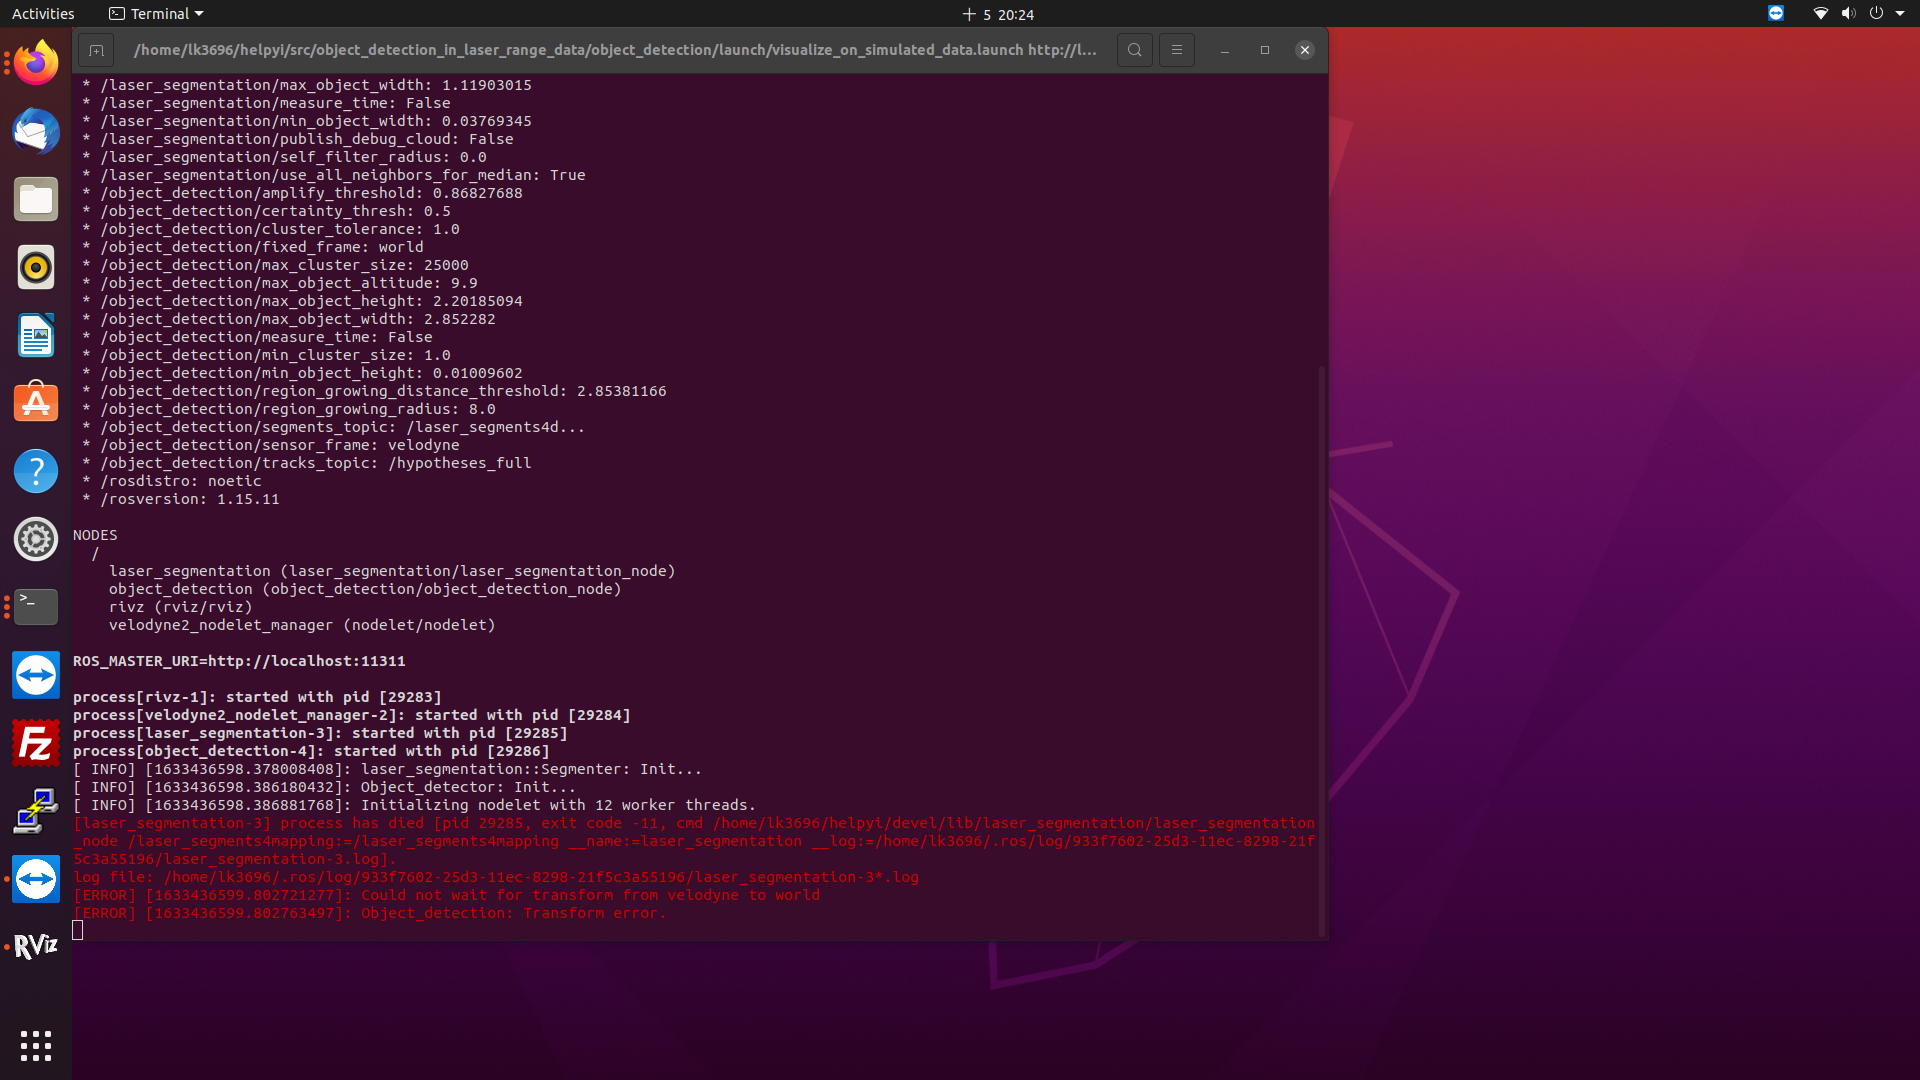
I try to change **ros::Duration()** but it didn't fix the problem.
After searching similar issues at community, I run this command:
**rosrun tf static_transform_publisher 0 0 0 0 0 0 world velodyne 10**
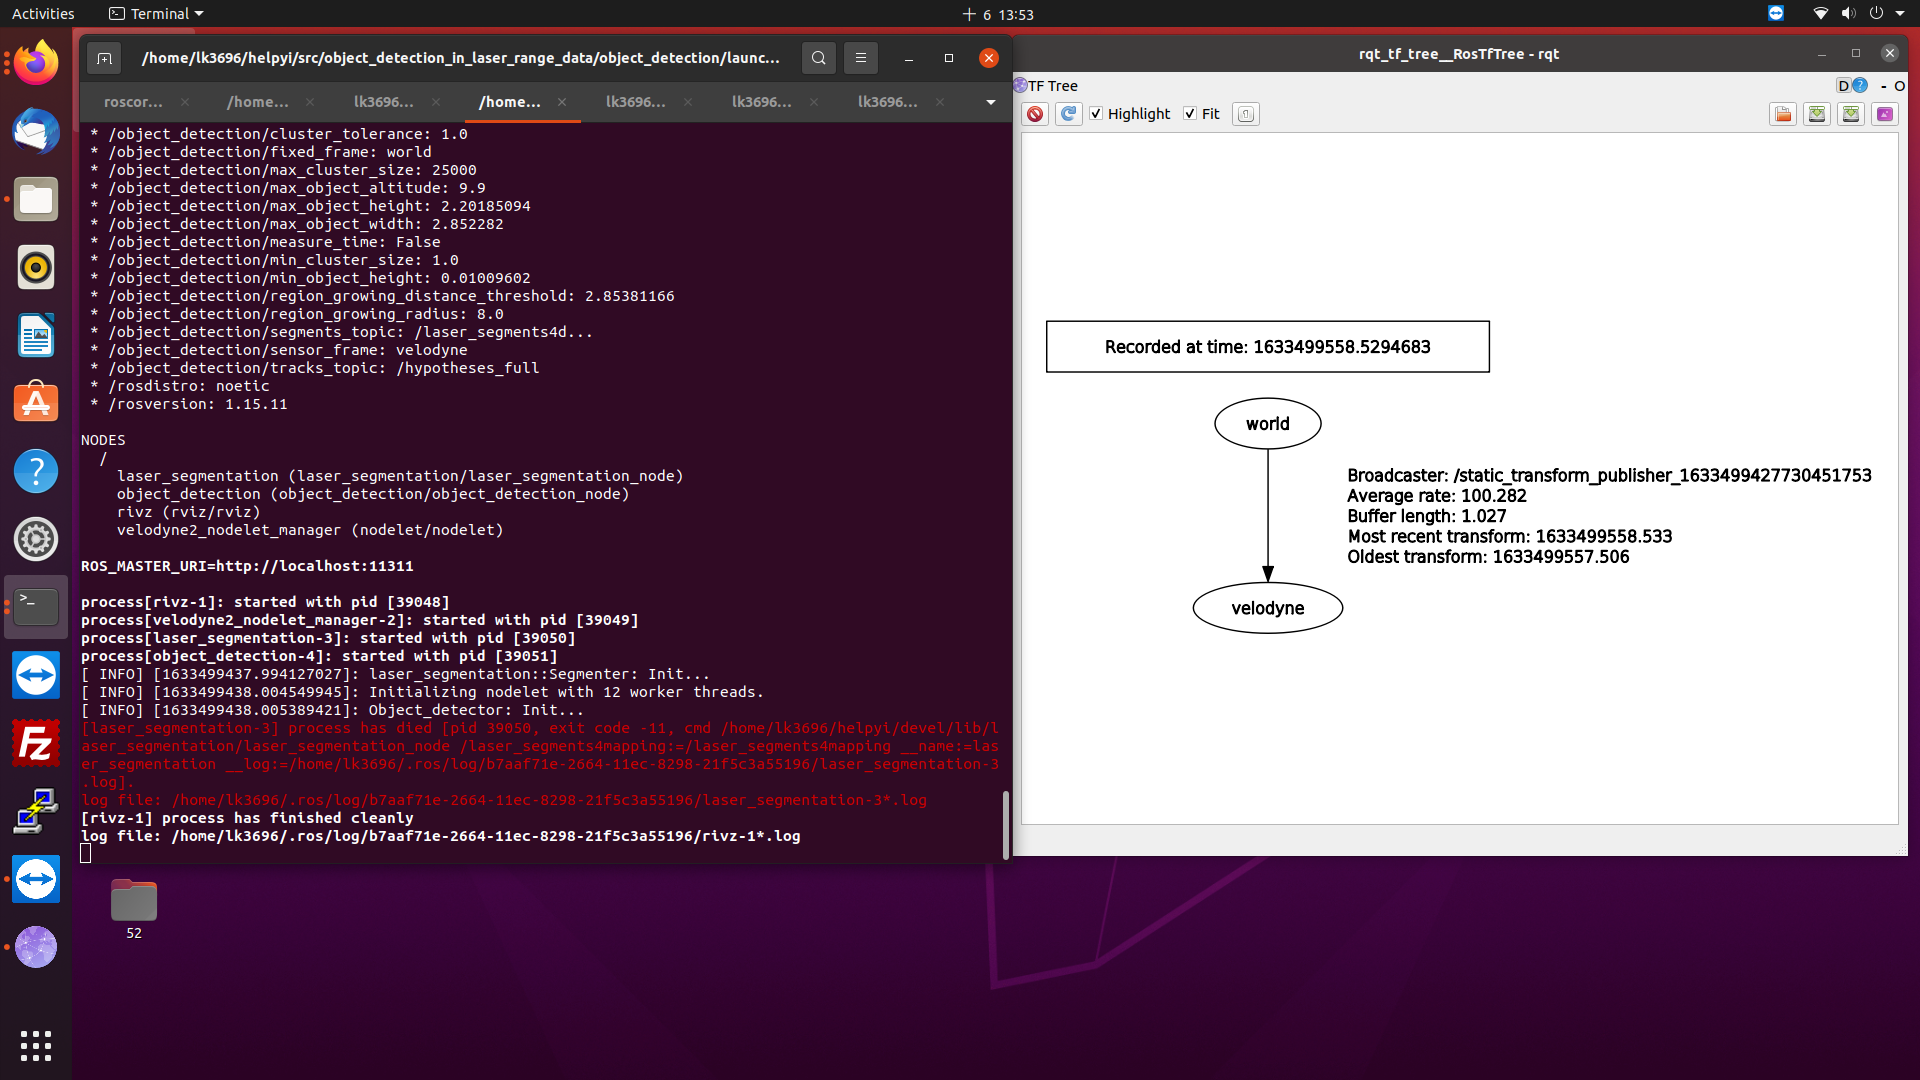
It seems that fix the transform error but still have the "process has died" problem.
Additionally, I can see the "Segmented Cloud" only at first frame.
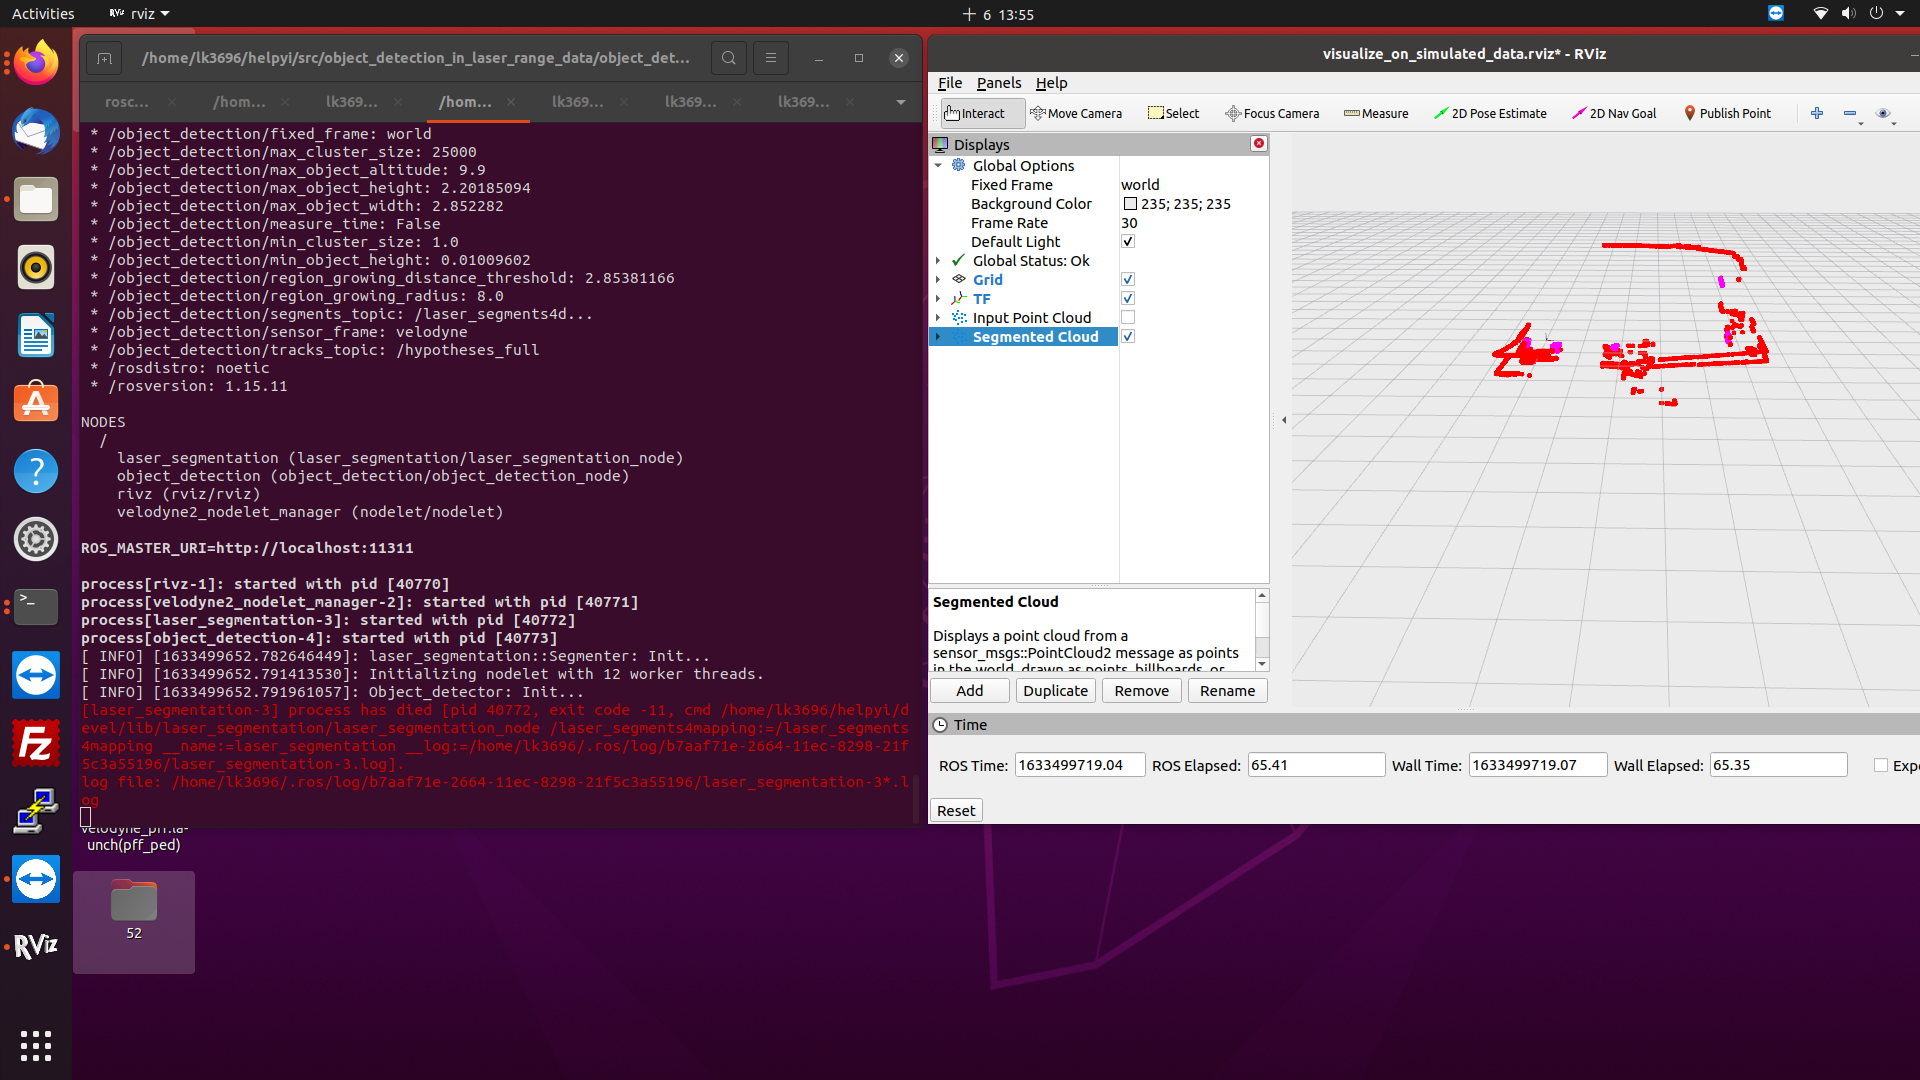
May i have your suggestions to fix this problem?
Any help is much appreciated:)
Guia de contribuição
Nenhum guia de contribuição indexado para este repositório
Avaliação
Esta issue ainda não foi avaliada.