pimoroni / pimoroni/vl53l1x-python
First readings deviation
Open
Nobody has claimed this yet.
- Dominant language
- C
- Stars
- 106
- Forks
- 58
- Avg merge
- 1h 17m
- Merged PRs (30d)
- 1
Description
Hi,
I've a question about first readings stability.
I'm running this example and here are results, which i got:
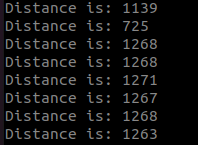
Even though the object was not moving the sensor returned an incorrect value for the first 2 readings (sometimes 3 or 4).
Do you have any clue how to solve this?
Contributor guide
No contributing guide indexed for this repository
First steps
- Read the whole issue, then the project's contributing guide.
- Comment on the issue to say you are picking it up — it saves two people doing the same work.
- Fork the repository and make your change on a branch.
- Open a pull request that references the issue number.
Research direction
Start with examples/distance.py and reproduce the reported first-reading behavior using the VL53L1X sensor. Trace the startup and measurement flow to determine whether the initial incorrect values come from the library or the sensor, then document the cause and a verified remedy.
Written by the indexing model from the issue text.
Assessment
- Tech stack
- python
- Domain
- embedded-iot
- Issue type
- Bug
- Difficulty
- 4/5
- Estimated time
- 3-5 days
- Activity status
- Stale
- Clarity
- Needs clarification
- Newbie friendliness
- 30/100