How to implement point cloud affine registration?
- Dominant language
- C++
- Stars
- 14k
- Forks
- 2.6k
- Avg merge
- 5d 18h
- Merged PRs (30d)
- 6
Description
### Checklist
- [X] I have searched for [similar issues](https://github.com/isl-org/Open3D/issues).
- [X] For Python issues, I have tested with the [latest development wheel](http://www.open3d.org/docs/latest/getting_started.html#development-version-pip).
- [X] I have checked the [release documentation](http://www.open3d.org/docs/release/) and the [latest documentation](http://www.open3d.org/docs/latest/) (for `master` branch).
### My Question
I am learning the point cloud registration by the [document](http://www.open3d.org/docs/latest/tutorial/pipelines/global_registration.html).
The provided demo search the transform with `rotation angle` and `translation`. But, I want to search a scale parameters.
For example, the original registration point is:
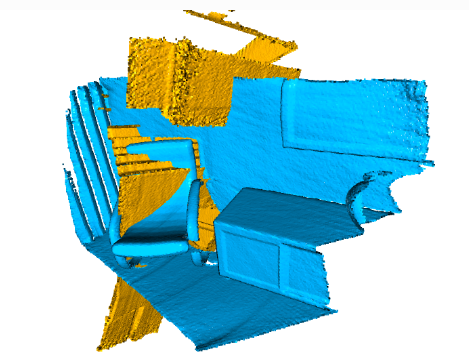
If I modify the transform matrix to:
```
trans_init = np.asarray([[0.0, 0.0, 2.0, 0.0],
[2.0, 0.0, 0.0, 0.0],
[0.0, 2.0, 0.0, 0.0],
[0.0, 0.0, 0.0, 1.0]])
```
and the visualization result is:
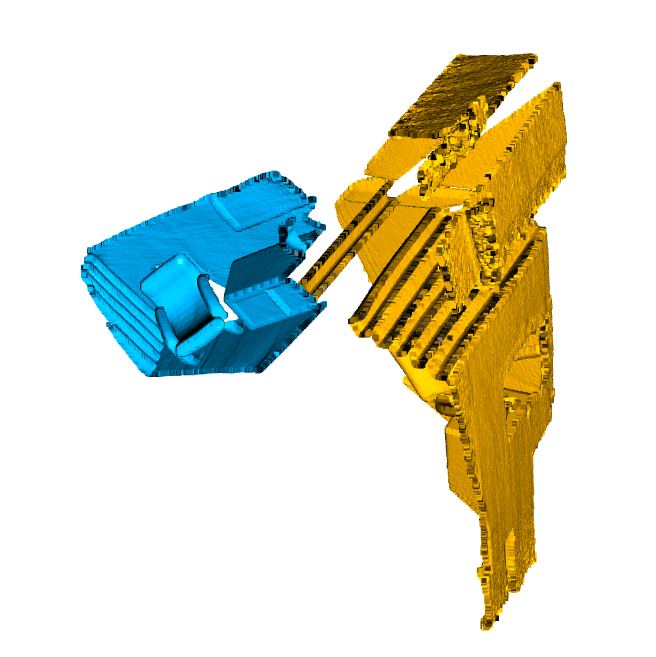
Then, the registration result is:
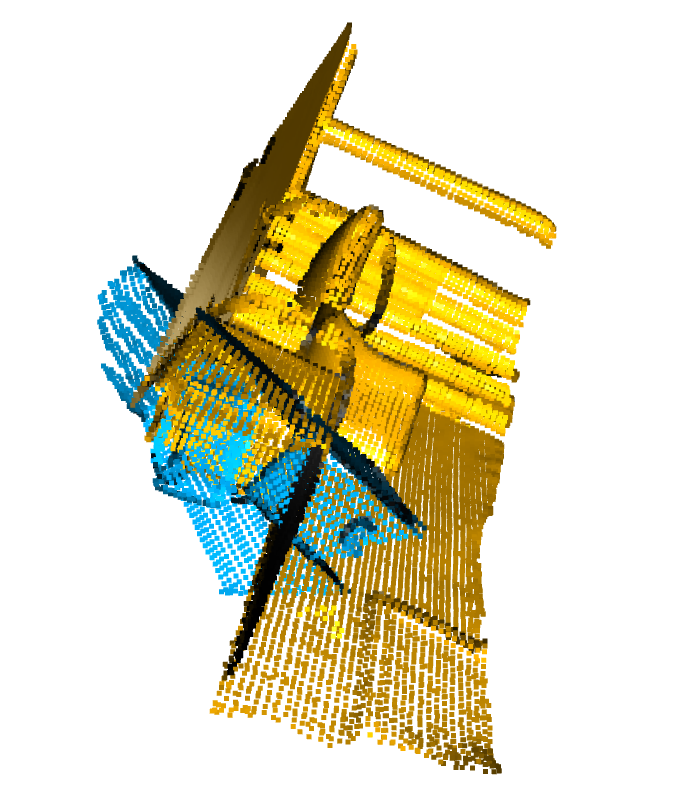
The registration result is obsolutely wrong. The reason is that the demo only conside a rigid registration rather than a affine registration.
How can I implement a affine registration with `open3d`? Any suggestion is appreciated~~~
Contributor guide
No contributing guide indexed for this repository
Assessment
This issue has not been assessed yet.