Reconstruction issue with PointCloud.create_from_rgbd_image
- Dominant language
- C++
- Stars
- 14k
- Forks
- 2.6k
- Avg merge
- 5d 18h
- Merged PRs (30d)
- 6
Description
### Checklist
- [X] I have searched for [similar issues](https://github.com/isl-org/Open3D/issues).
- [X] For Python issues, I have tested with the [latest development wheel](http://www.open3d.org/docs/latest/getting_started.html#development-version-pip).
- [X] I have checked the [release documentation](http://www.open3d.org/docs/release/) and the [latest documentation](http://www.open3d.org/docs/latest/) (for `master` branch).
### My Question
Hi, I am having issue with the result of my 3D model reconstruction. I would like to have some insight :)
In order to use PointCloud.create_from_rgbd_image function, I have DRONE images (RGB), Depth Images, Camera calibration (intrinsic), and extrinsic which the camera pose. The camera pose has been calculated not by getting drone odometry/telemetry but by using Feature matching using ORB algorithm. This algorithm provides very accurate on KITTI dataset for pose estimation.
So after feeding that function with all the necessary inputs I have the result bellow.
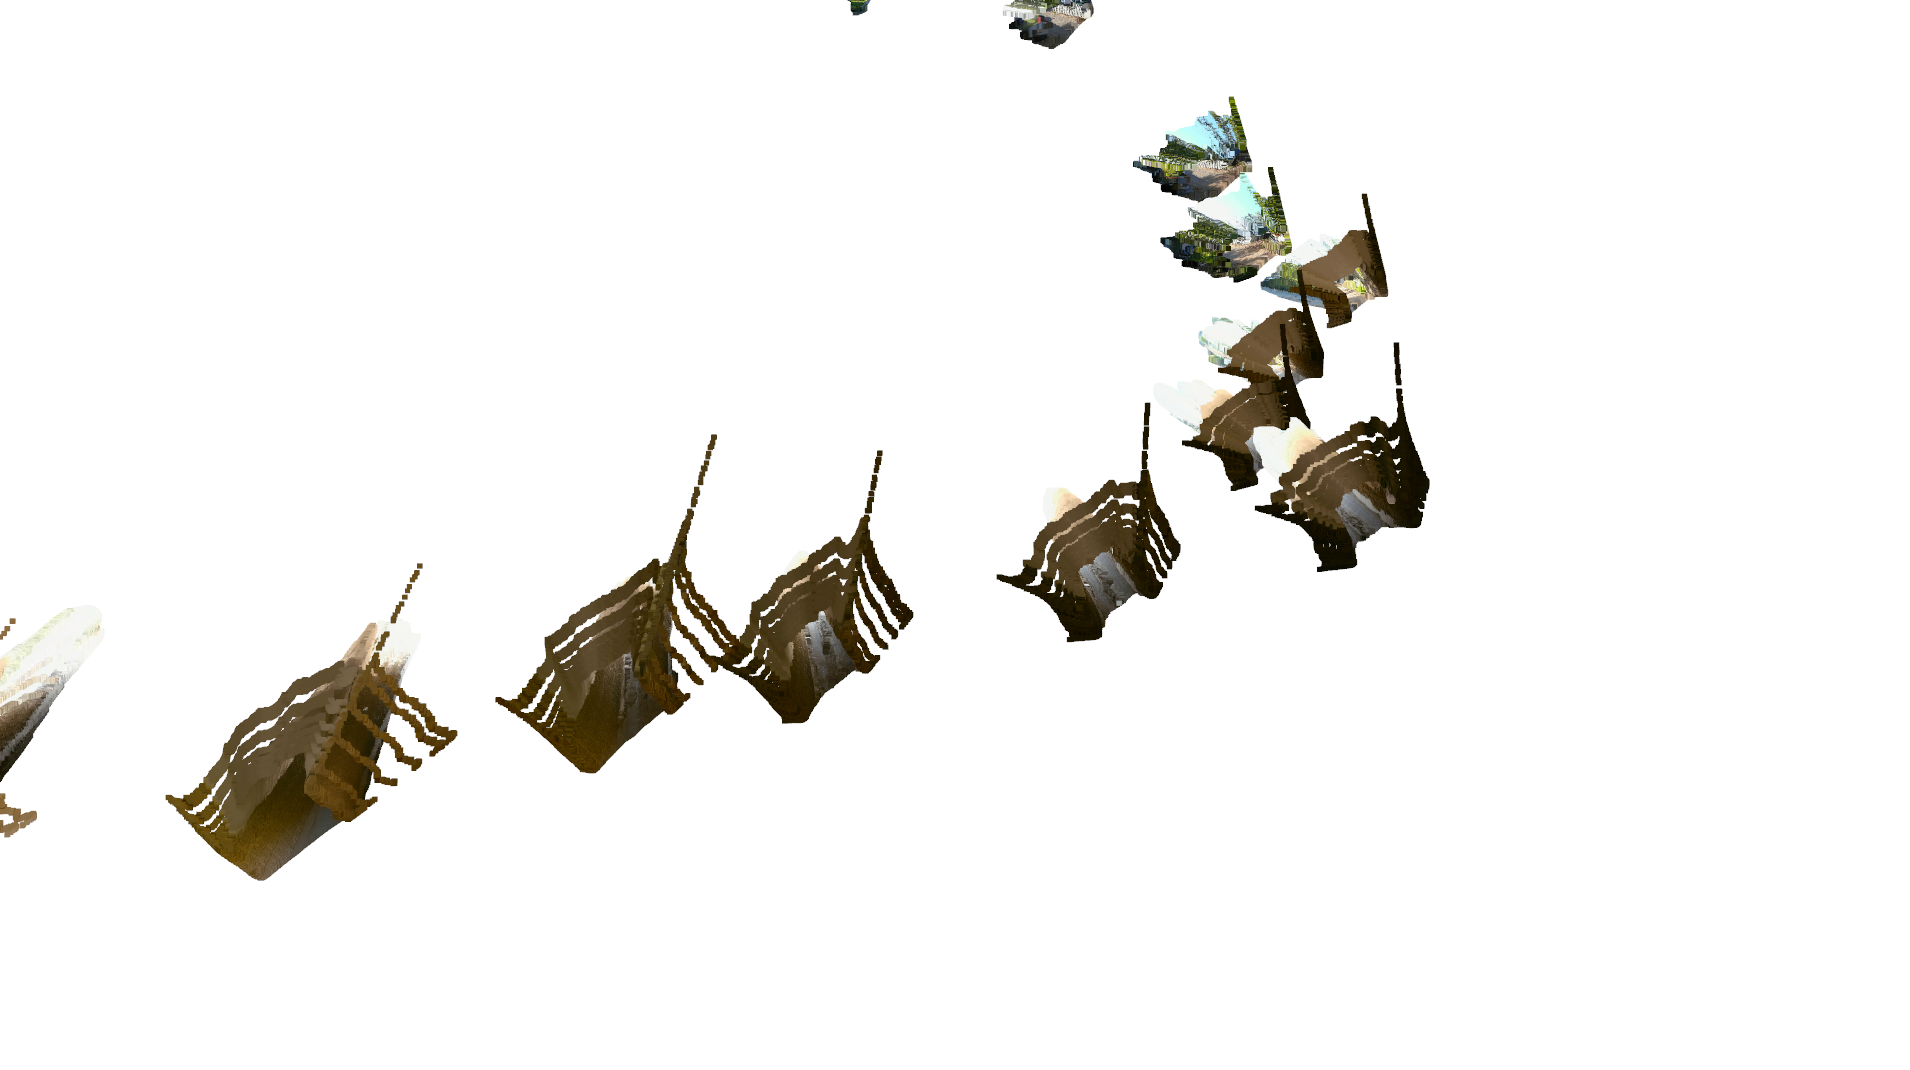
I would like to understand why it is scattered like this and why axis are reserved? And of course, what should I do to have a smooth and clean model. Many thanks !~
Contributor guide
No contributing guide indexed for this repository
Assessment
This issue has not been assessed yet.