extract the pose from trajectory file in feed into colmap
- Dominant language
- C++
- Stars
- 14k
- Forks
- 2.6k
- Avg merge
- 5d 18h
- Merged PRs (30d)
- 6
Description
### Checklist
- [X] I have searched for [similar issues](https://github.com/isl-org/Open3D/issues).
- [X] For Python issues, I have tested with the [latest development wheel](http://www.open3d.org/docs/latest/getting_started.html#development-version-pip).
- [X] I have checked the [release documentation](http://www.open3d.org/docs/release/) and the [latest documentation](http://www.open3d.org/docs/latest/) (for `master` branch).
### My Question
Hi, i came across the trajectory.log after 'reconstruction system.py'. it contains 4x4 transformation matrix
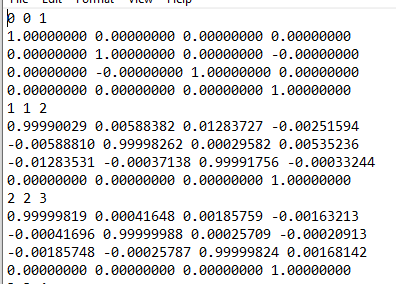
If i understand correctly, it is transformed from rotation in quaternion and translation
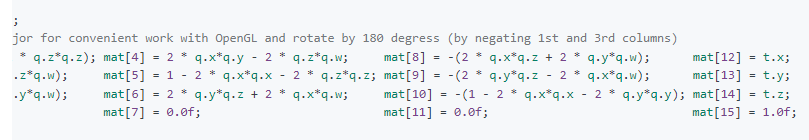
So, i tried to convert it back to quaternion and translation ('Qw','Qx','Qy','Qz','Tx','Ty','Tz',) using the equations in the image as known parameters in colmap for sparse and dense reconstrction.
However, reconstruction failed in colmap, so I would like to know if the transformation i did from the 4x4 matrix back to quaternion correct?
many thanks
Contributor guide
No contributing guide indexed for this repository
Assessment
This issue has not been assessed yet.