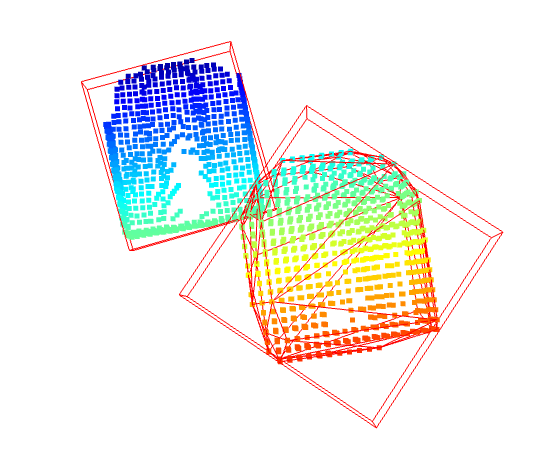
Oriented bounding box estimates are quite off
- Dominant language
- C++
- Stars
- 14k
- Forks
- 2.6k
- Avg merge
- 5d 18h
- Merged PRs (30d)
- 6
Description
### Checklist
- [X] I have searched for [similar issues](https://github.com/isl-org/Open3D/issues).
- [X] For Python issues, I have tested with the [latest development wheel](http://www.open3d.org/docs/latest/getting_started.html#development-version-pip).
- [X] I have checked the [release documentation](http://www.open3d.org/docs/release/) and the [latest documentation](http://www.open3d.org/docs/latest/) (for `master` branch).
### My Question
Hi, I have a partial point cloud, and a point cloud of better quality. However, when I run the oriented bounding box by calling pcd.get_oriented_bounding_box(robust=True), and visualize the results for both point clouds, the estimation for the better point cloud are even worse than the more partial-viewed cloud. I'm curious about how this is happening. Any suggestions and ideas are greatly appreciated!
Contributor guide
No contributing guide indexed for this repository
Assessment
This issue has not been assessed yet.