RealsenseBagReader depth off
- Dominant language
- C++
- Stars
- 14k
- Forks
- 2.6k
- Avg merge
- 5d 18h
- Merged PRs (30d)
- 6
Description
**Describe the bug**
Trying the realsense examples available in [Documenation/Sensor example](http://www.open3d.org/docs/release/tutorial/sensor/realsense.html). I have download the test dataset and RealSenseBagReader is built.
Executing the `RealSenseBagReader`, opens a GUI with split window with rgb on the left and depth on the right. The depth on the right is one flat color except edges assuming this is not a correct version or some other steps need to be introduced.
Moreover dataset seems to be different from those on the example site.
**To Reproduce**
`cd open3d` folder
`python examples/python/reconstruction_system/scripts/download_dataset.py L515_test`
`build/bin/examples/RealSenseBagReader --input ../datasets/L515_test/L515_test.bag`
**Expected behavior**
Depth image should be not a flat color with only edges appearing where no depth information is present
**Screenshots**
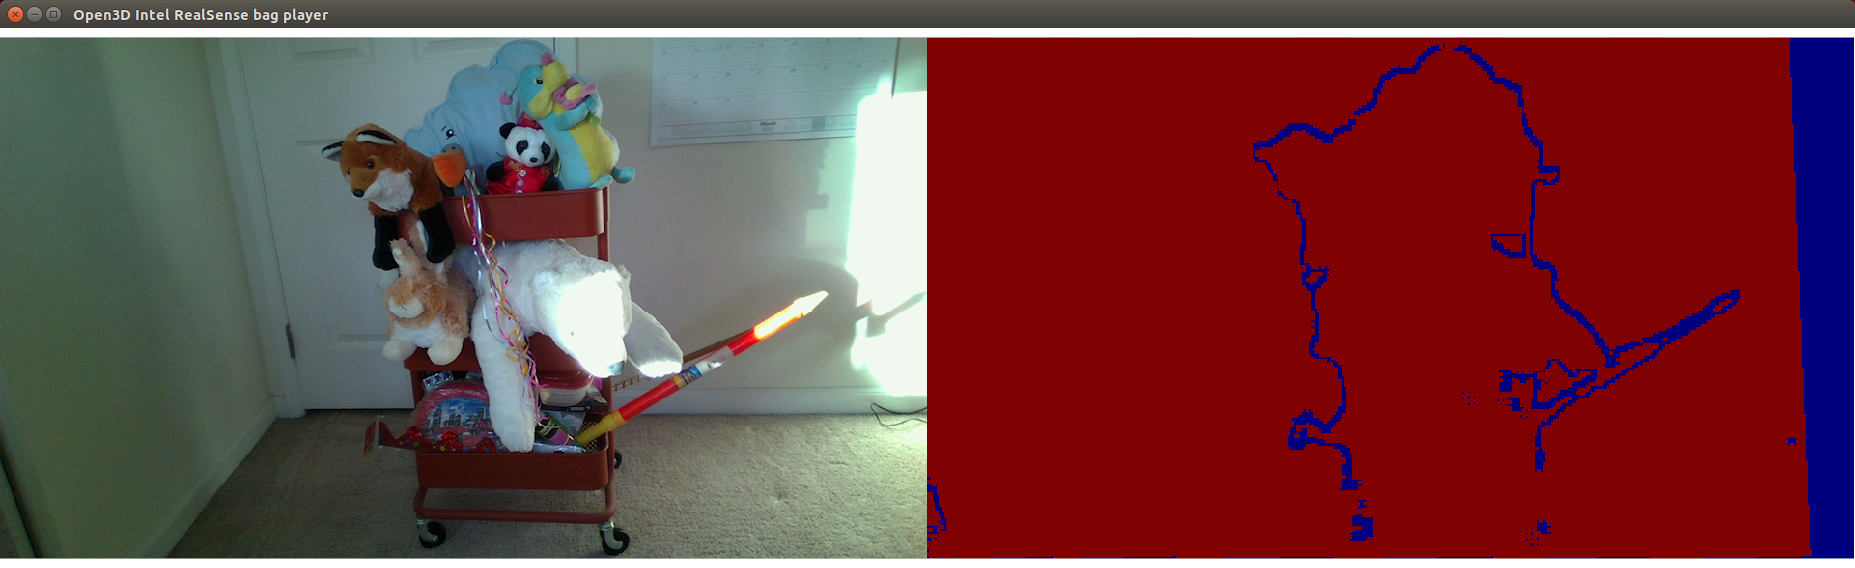
**Environment (please complete the following information):**
- Operating system: Ubuntu 18.04
- Python version: Python 3.9.6
- Open3D version: 0.13
- Is this remote workstation?: no
- How did you install Open3D?: build from source
- Compiler version (if built from source): e.g. gcc 7.5,
**Additional context**
This problem is about L515_test and possible L515_paper_lantern dataset. L515_JackJack seems to be unaffected
Contributor guide
No contributing guide indexed for this repository
Assessment
This issue has not been assessed yet.