point cloud creation from interiornet dataset is skewed
- Dominant language
- C++
- Stars
- 14k
- Forks
- 2.6k
- Avg merge
- 5d 18h
- Merged PRs (30d)
- 6
Description
Hi, I am trying to create a point cloud from the Interiornet RGBD images, following the code snippet below:
```
import open3d as o3d
color = o3d.io.read_image('./rgb.png')
depth = o3d.io.read_image('./depth.png')
intrinsics = o3d.io.read_pinhole_camera_intrinsic("./camera_intrinsics.json")
rgbd = o3d.geometry.RGBDImage.create_from_color_and_depth(color, depth, depth_trunc=4.0, convert_rgb_to_intensity=False)
pcd = o3d.geometry.PointCloud.create_from_rgbd_image(rgbd, o3d.camera.PinholeCameraIntrinsic(intrinsics))
pcd.transform([[1, 0, 0, 0], [0, -1, 0, 0], [0, 0, -1, 0], [0, 0, 0, 1]])
o3d.visualization.draw_geometries([pcd])
```
However, for some reason my point cloud is skewed:
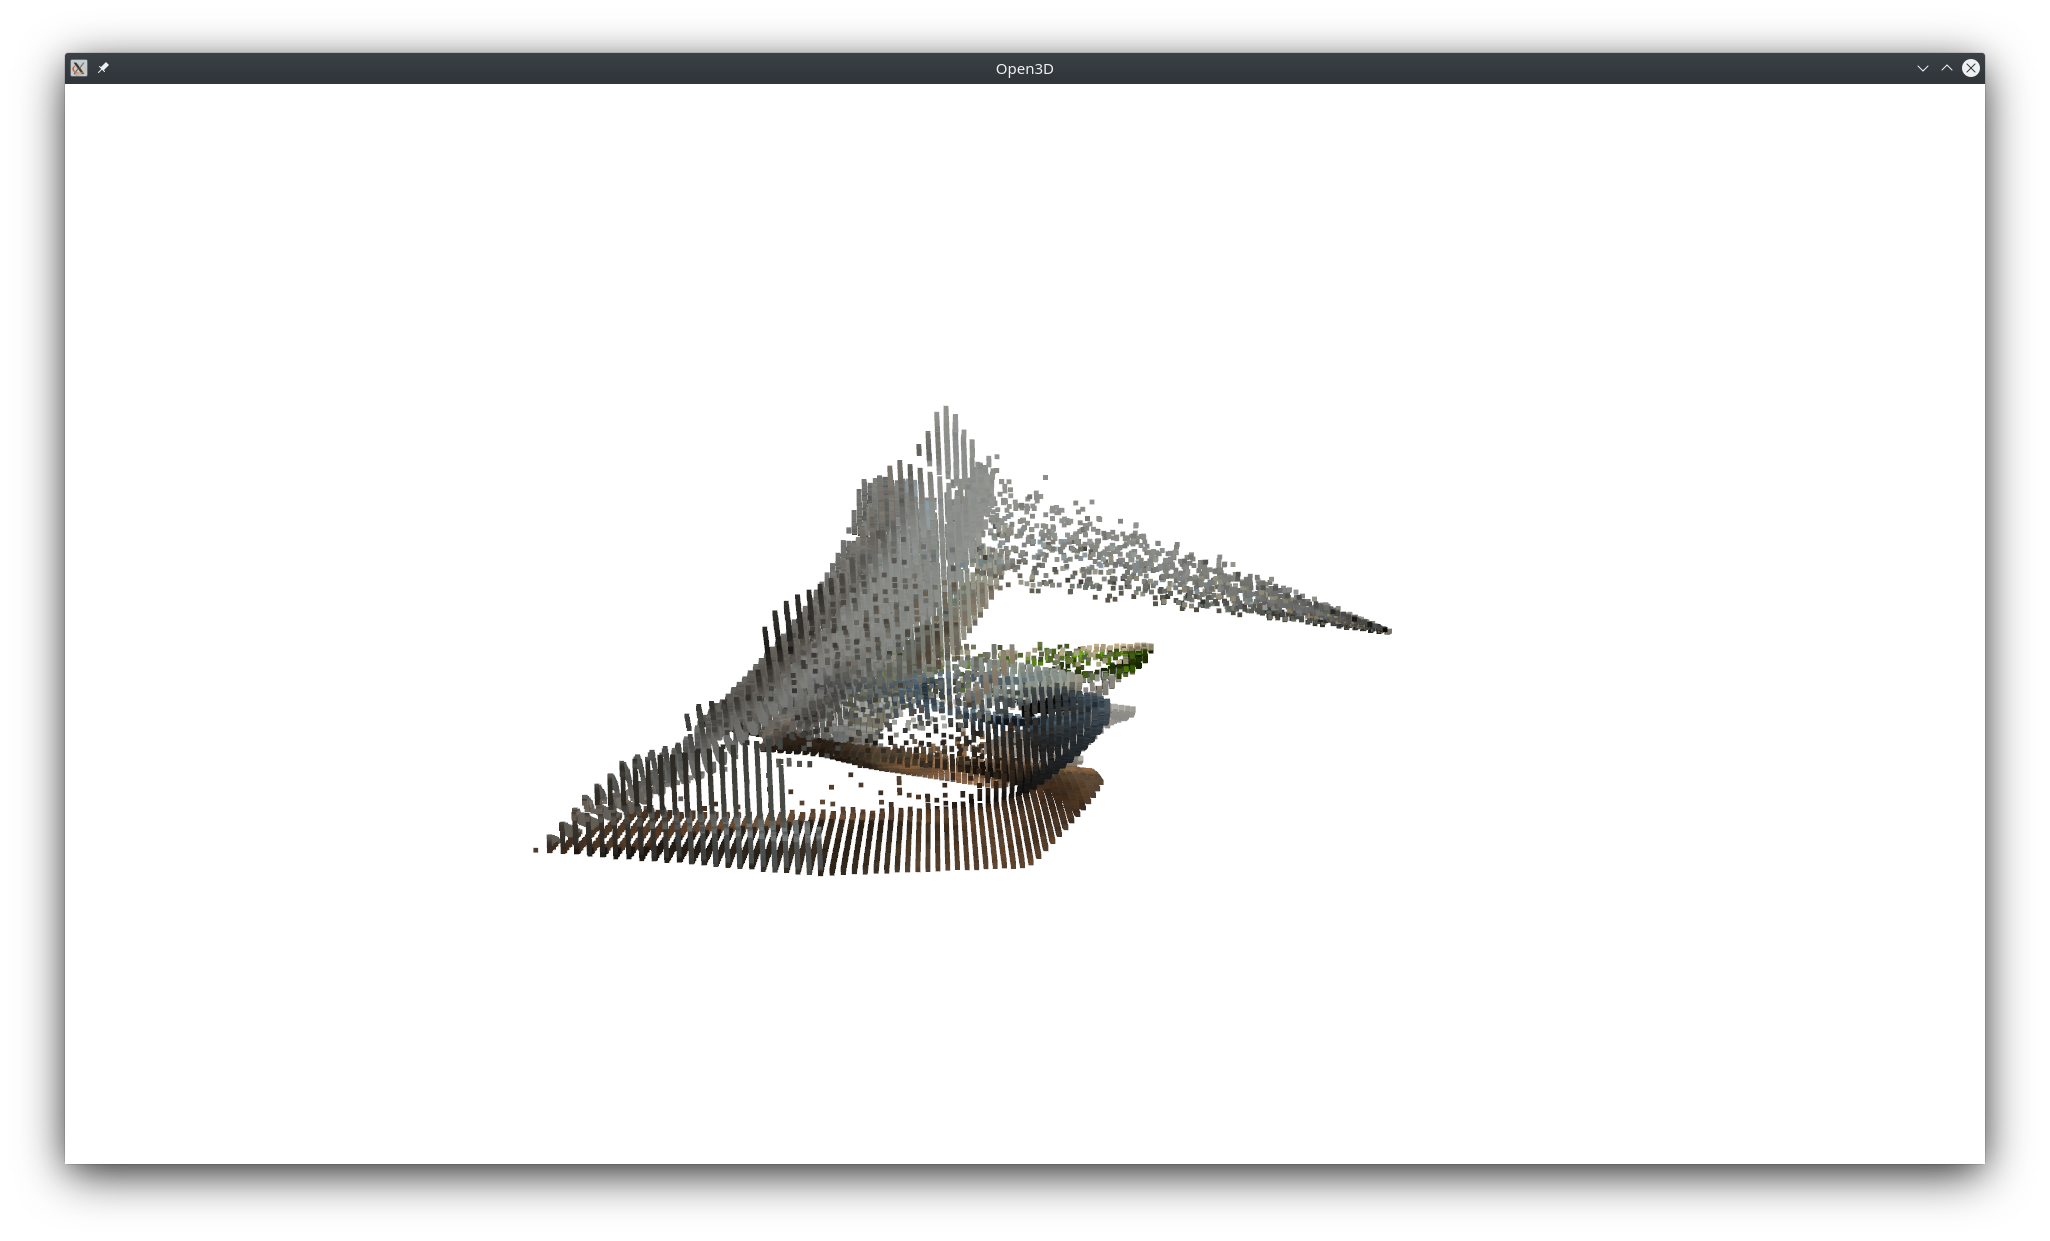
Any idea what could be wrong?
Environment:
- Operating system: Archlinux
- Python version: Python 3.8
- Open3D version: 0.10.0.0
- Is this remote workstation?: no
- How did you install Open3D?: pip
I am attaching a pair of rgbd images and the intrinsics file.
[open3d_reconstruction_system.zip](https://github.com/intel-isl/Open3D/files/5044014/open3d_reconstruction_system.zip)
Contributor guide
No contributing guide indexed for this repository
Assessment
This issue has not been assessed yet.