godotengine / godotengine/godot-docs
RigidBody2D incorrectly states impulse rotation is in global space.
- Dominant language
- reStructuredText
- Stars
- 5.7k
- Forks
- 3.8k
- Avg merge
- 1d 20h
- Merged PRs (30d)
- 25
Description
**Your Godot version:**
3.2.3
**Issue description:**
> The position uses the rotation of the global coordinate system, but is centered at the object's origin.
First of all this is super weirdly worded and needs to be improved.
But even then, given a RigidBody2D rotated 90° with this code:
```py
func _physics_process(delta):
apply_impulse(Vector2.RIGHT * 100.0, Vector2.DOWN)
```
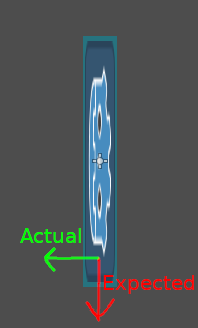
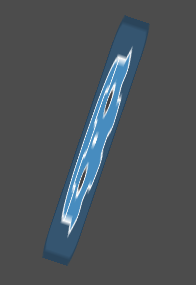
A torque is applied:
**URL to the documentation page:**
https://docs.godotengine.org/en/stable/classes/class_rigidbody2d.html#class-rigidbody2d-method-apply-impulse
Contributor guide
No contributing guide indexed for this repository
Assessment
This issue has not been assessed yet.