ArduPilot / ArduPilot/MissionPlanner
Plan: ATTITUDE_TIME climb rate field reset to zero
- Dominant language
- C#
- Stars
- 2.4k
- Forks
- 2.9k
- Avg merge
- 19h 16m
- Merged PRs (30d)
- 4
Description
Similar to https://github.com/ArduPilot/MissionPlanner/issues/2871 the Plan screen resets the ATTITUDE_TIME message's "ClimbRate" field to zero after it is written and then read back from the autopilot.
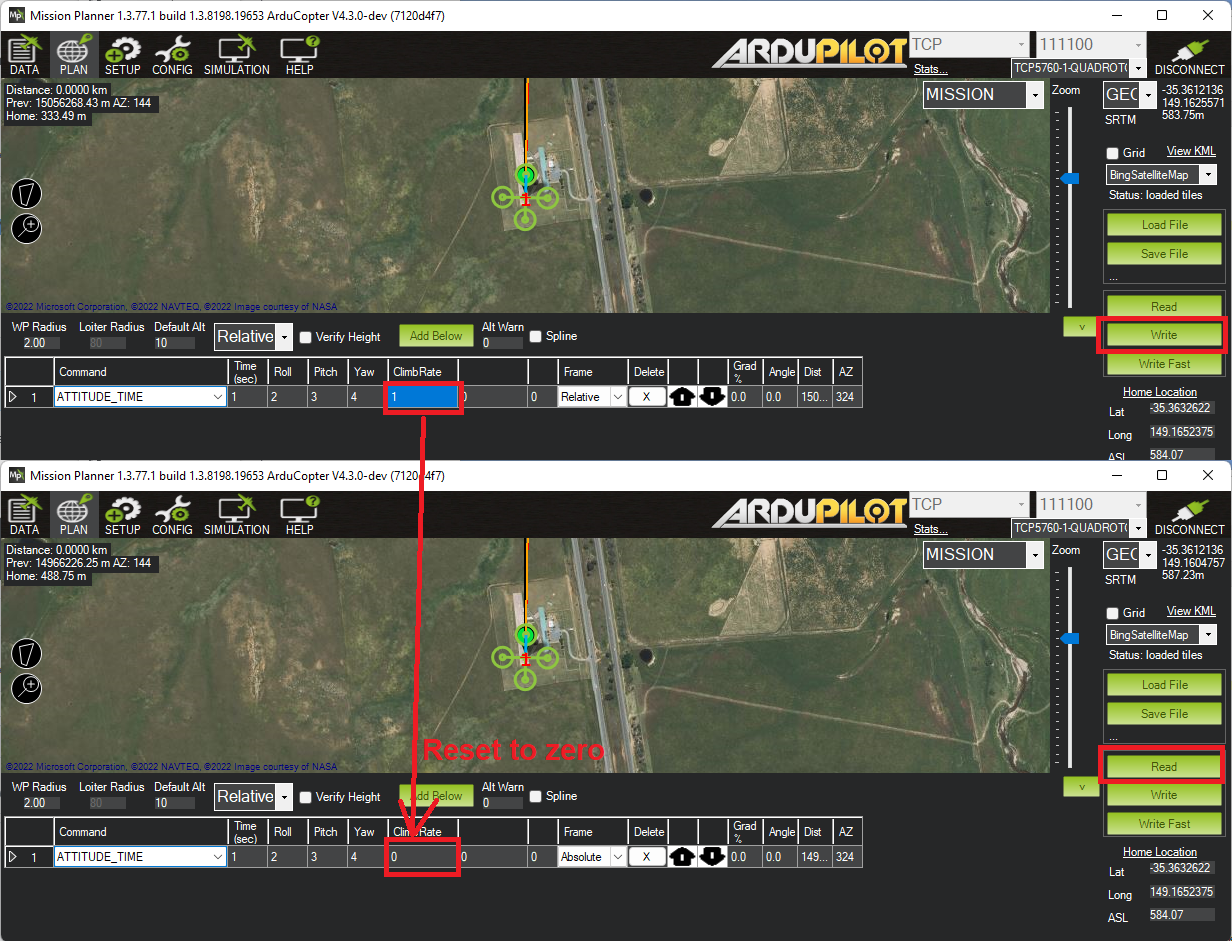
I suspect we will find the same thing happens to the DO_GIMBAL_MANAGER_PITCHYAW command once PR https://github.com/ArduPilot/MissionPlanner/pull/2882 is merged.
Contributor guide
No contributing guide indexed for this repository
Research direction
Start by comparing this report with MissionPlanner issue 2871 and tracing the Plan screen handling of the ATTITUDE_TIME message's ClimbRate field. Reproduce the write/read-back flow shown in the report, then verify that the value is retained instead of reset to zero; also check whether the related DO_GIMBAL_MANAGER_PITCHYAW case is covered after PR 2882.
Written by the indexing model from the issue text.
Assessment
- Tech stack
- csharp
- Domain
- desktop
- Issue type
- Bug
- Difficulty
- 3/5
- Estimated time
- 1-2 days
- Activity status
- Stale
- Clarity
- Mostly clear
- Newbie friendliness
- 35/100