ArduPilot / ArduPilot/MissionPlanner
SLCan passthrough mode stopped working
- Dominant language
- C#
- Stars
- 2.4k
- Forks
- 2.9k
- Avg merge
- 19h 16m
- Merged PRs (30d)
- 4
Description
#### Issue details
SLCan passthrough mode worked for me last spring (April) and once today, but other than that, I can't get it to work. I am following the [directions](https://docs.cubepilot.org/user-guides/here-3/here-3-manual#2.-here3-u-blox-chip-firmware-update) to update the u-blox firmware in the Here 3 GPS with a CubeOrange.
- Go to UAVCAN page
- Enable SLCan mode CAN1
- It connects
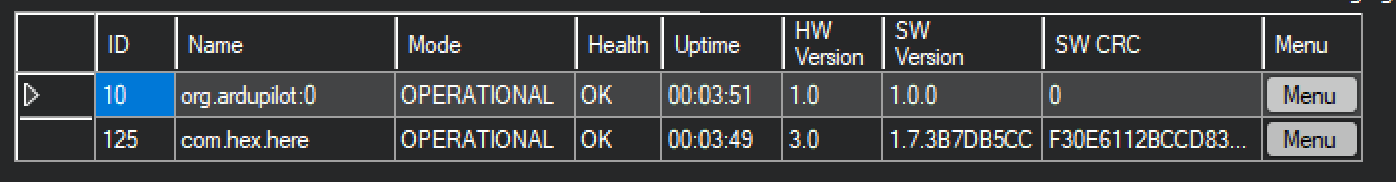
- go to parameters and set passThrough to 2

- Write Parameters
- Commit Parameters
- Close parameters dialog
- Restart the GPS (verify uptime has restarted)
- enable CAN passthrough mode - select port 500
- Start u-center v21.02
- Create new or select existing connection - tcp://127.0.0.1:500
- If the connection is working, there is an icon for the connection in the status bar that will blink. if it is not blinking, the connection is not good.
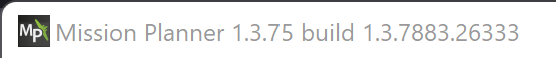
#### Version
#### Platform
[ ] All
[ ] AntennaTracker
[ x ] Copter
[ ] Plane
[ ] Rover
[ ] Sub
#### Airframe type
_What type of airframe (flying wing, glider, hex, Y6, octa etc)_
#### Hardware type
CubeOrange
#### Logs
I will try to get logs of a working and not working session tomorrow.
Contributor guide
No contributing guide indexed for this repository
Research direction
Start with the UAVCAN page and reproduce the CAN1 SLCan, passThrough=2, GPS restart, port 500, and u-center tcp://127.0.0.1:500 sequence described in the issue. Compare working and failing sessions and collect the promised logs; done means the connection remains usable and the u-center status icon blinks reliably.
Written by the indexing model from the issue text.
Assessment
- Tech stack
- csharp
- Domain
- desktop, networking
- Issue type
- Bug
- Difficulty
- 4/5
- Estimated time
- 3-5 days
- Activity status
- Stale
- Clarity
- Mostly clear
- Newbie friendliness
- 35/100