ArduPilot / ArduPilot/MissionPlanner
UDPCi not detecting heartbeat in 1.3.74
- Dominant language
- C#
- Stars
- 2.4k
- Forks
- 2.9k
- Avg merge
- 19h 16m
- Merged PRs (30d)
- 4
Description
#### Issue details
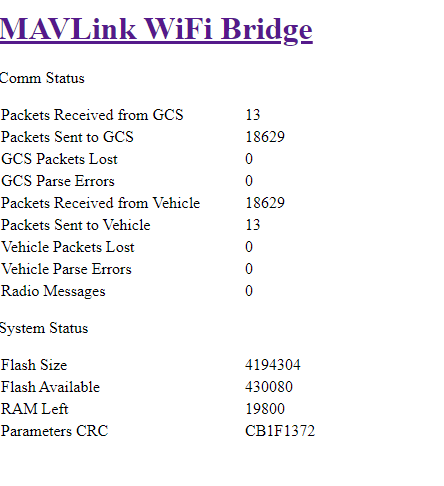
UDPCi does not connect to mavlink 8266. This worked well in 1.3.73. There is a new behavior when I restart mission planner, it automatically tries to connect by UDP to the Mavlink in client mode. It connects and updates the hud, but no parameters are downloaded. If I disconnect and try to reconnect using UDP only setting, it fails as expected. When I try to connect with UDPCi, i see the initial request go to the Mavlink bridge, mavlink data is being sent through the mavlink bridge, it just isn't being received by MP.
#### Version
1.3.74
#### Platform
[ ] All
[ ] AntennaTracker
[ ] Copter
[ ] Plane
[ x ] Rover
[ ] Sub
#### Airframe type
_What type of airframe (flying wing, glider, hex, Y6, octa etc)_
rover
#### Hardware type
_What autopilot hardware was used? (pixhawk, pixracer, PX4FMU etc)_
pixhawk
#### Logs
_Please provide a link to any relevant logs that show the issue_
Contributor guide
No contributing guide indexed for this repository
Research direction
Reproduce the issue in Mission Planner 1.3.74 with a Rover, Pixhawk, and Mavlink 8266 using the UDP and UDPCi connection modes described. Compare behavior with 1.3.73; done means UDPCi receives the heartbeat and downloads parameters after the Mavlink bridge sends data.
Written by the indexing model from the issue text.
Assessment
- Tech stack
- csharp
- Domain
- desktop, networking
- Issue type
- Bug
- Difficulty
- 4/5
- Estimated time
- 3-5 days
- Activity status
- Stale
- Clarity
- Mostly clear
- Newbie friendliness
- 35/100