ArduPilot / ArduPilot/MissionPlanner
Compass priorisation table's orientation field does not match COMPASS_ORIENT parameter
- Dominant language
- C#
- Stars
- 2.4k
- Forks
- 2.9k
- Avg merge
- 19h 16m
- Merged PRs (30d)
- 4
Description
The Compass priorisation table's orientation field does not match COMPASS_ORIENT parameter as shown below

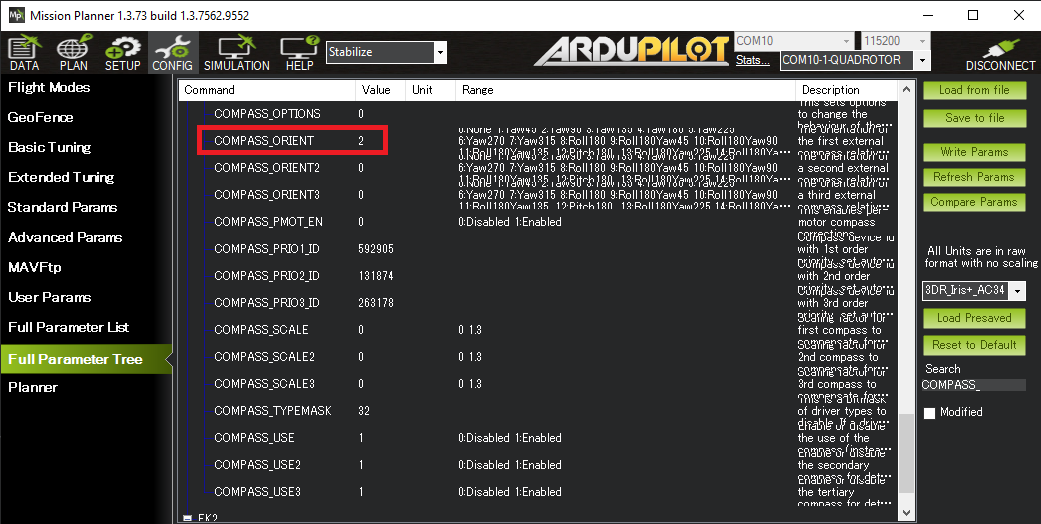
I've reproduced the issue by doing this on a CubeBlack using Copter-4.1.0-dev
- Connect with MP
- Open the Setup >> Mandadtory Hardware >> Compass screen and check the top compass's orientation field (it may always be None)
- Go to the Config >> Full Parameter Tree screen and change COMPASS_ORIENT = 2 (Yaw90)
- Go back and check MP's Compass prioritisation screen and note the Orientation is still "None"
- Reboot the autopilot, restart MP, reconnect and check the Compass priorisation screen and note that even after a reboot the top compass's orientation is still "None".
This issue was reported by David Artis [here in the Copter-4.0.4-rc4 testing thread](https://discuss.ardupilot.org/t/copter-4-0-4-rc4-available-for-beta-testing/60983/9).
Contributor guide
No contributing guide indexed for this repository
Research direction
Reproduce the issue in Mission Planner by following the listed Compass and Full Parameter Tree steps, changing COMPASS_ORIENT to 2 (Yaw90), then checking the Compass prioritisation screen before and after reboot. Trace how the Compass prioritisation screen obtains its orientation and compare it with the COMPASS_ORIENT parameter; done when the displayed orientation matches the parameter after changes and reconnection.
Written by the indexing model from the issue text.
Assessment
- Tech stack
- csharp
- Domain
- desktop
- Issue type
- Bug
- Difficulty
- 3/5
- Estimated time
- 1-2 days
- Activity status
- Stale
- Clarity
- Mostly clear
- Newbie friendliness
- 45/100