ArduPilot / ArduPilot/MissionPlanner
auto grid survey waypoints are changed after klicking to accept. Why?
- Dominant language
- C#
- Stars
- 2.4k
- Forks
- 2.9k
- Avg merge
- 19h 16m
- Merged PRs (30d)
- 4
Description
#### Issue details
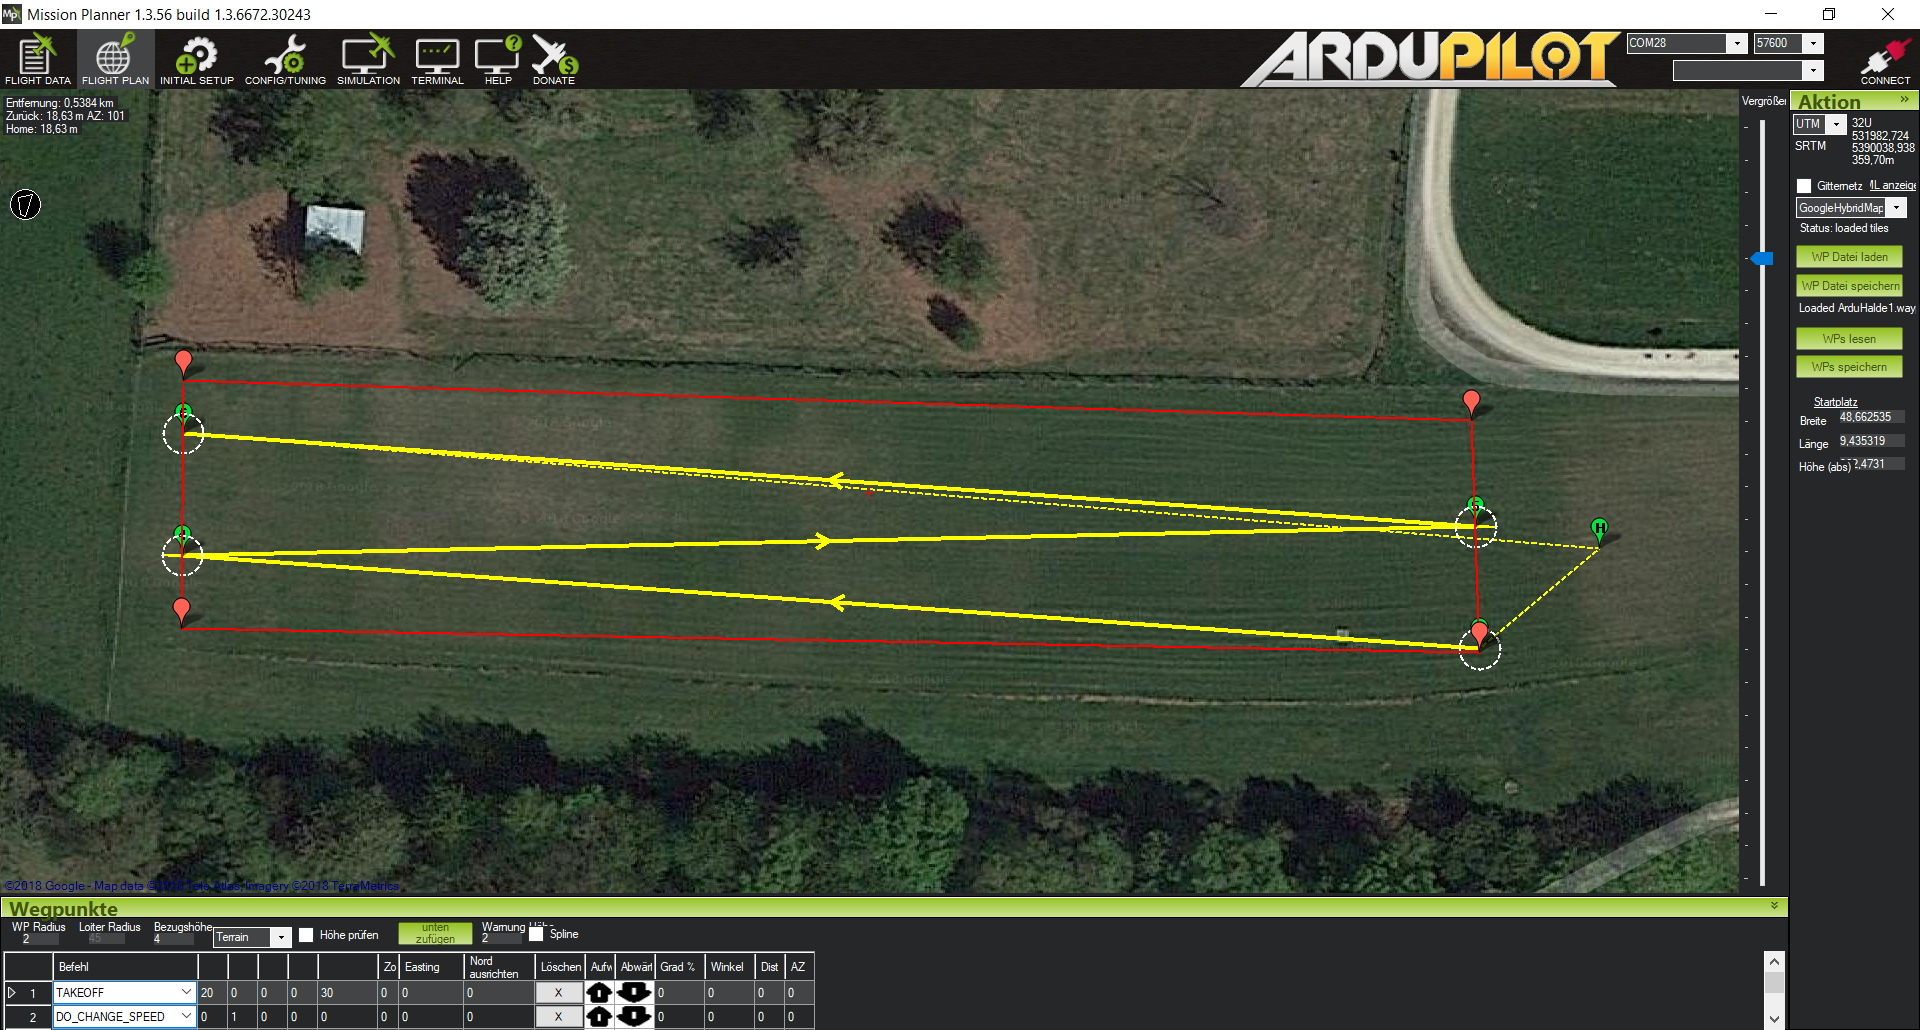
When I set a survey grid wit auto survey grid, it does show the waypoints correct, but if I klick to accept, the waypoints are set different:
#### Version
Mission Planner 1.3.56 build 1.3.6672.30243
#### Platform
[ ] All
[ ] AntennaTracker
[x ] Copter
[ ] Plane
[ ] Rover
[ ] Sub
#### Airframe type
_What type of airframe (flying wing, glider, hex, Y6, octa etc)_
Quad X
I want this waypoints:
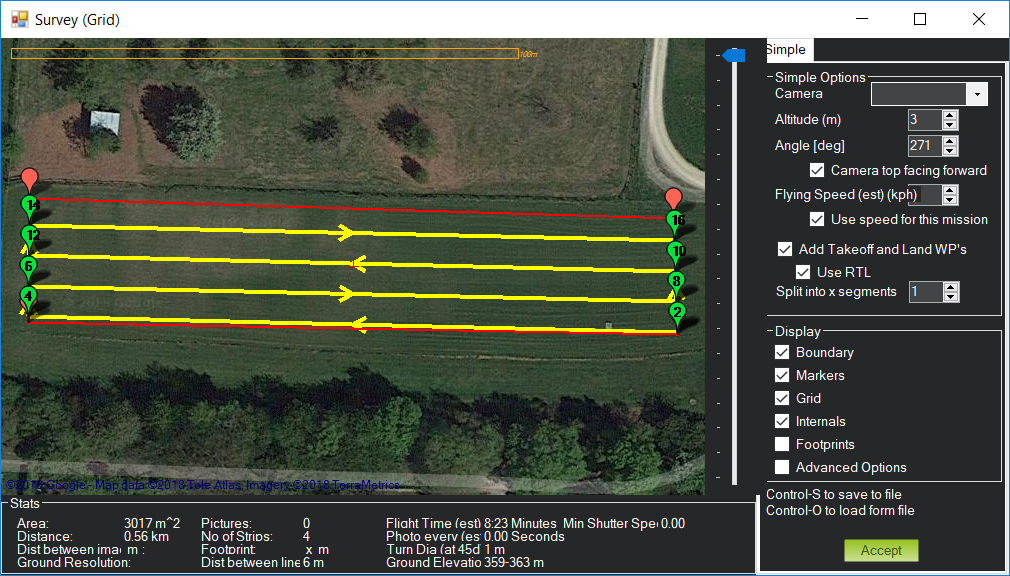
, but after klickint to accept, I get this waypoints. Why?
Contributor guide
No contributing guide indexed for this repository
Research direction
Reproduce the auto survey grid behavior in Mission Planner 1.3.56 build 1.3.6672.30243 on a Copter Quad X setup, comparing the displayed waypoints before and after clicking accept. The issue names no files, tests, or entry points; done means the accepted waypoints match the grid shown before confirmation.
Written by the indexing model from the issue text.
Assessment
- Tech stack
- csharp
- Domain
- desktop
- Issue type
- Bug
- Difficulty
- 4/5
- Estimated time
- 3-5 days
- Activity status
- Stale
- Clarity
- Needs clarification
- Newbie friendliness
- 20/100