ArduPilot / ArduPilot/MAVProxy
Map: Mission >> Loop clears waypoints if they haven't been saved
- Dominant language
- Python
- Stars
- 595
- Forks
- 773
- Avg merge
- 2d 6h
- Merged PRs (30d)
- 18
Description
Before:
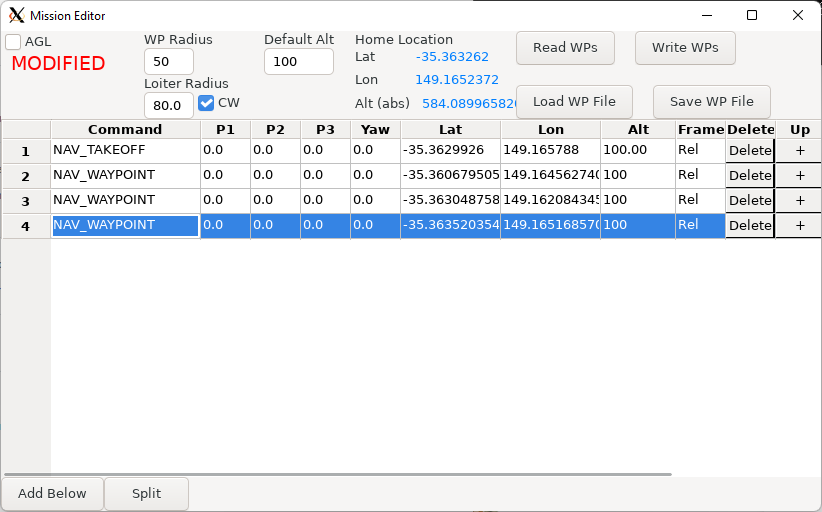
After right-mouse-button-click Mission >> Loop:
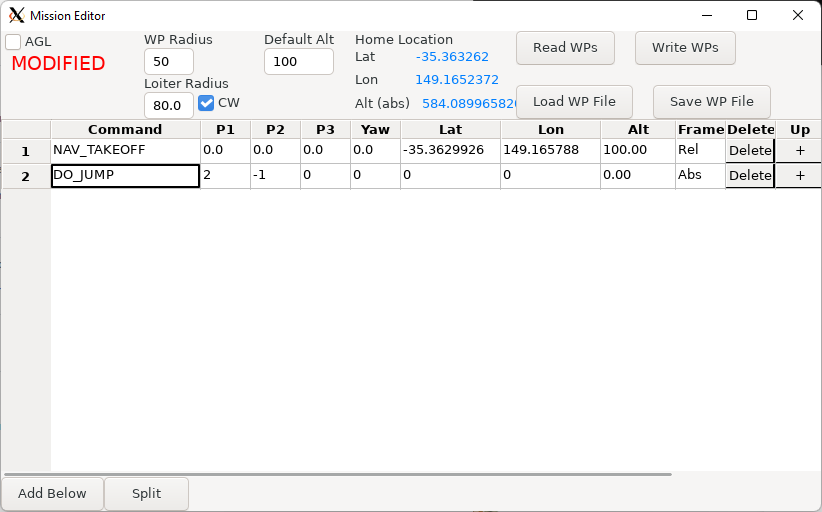
If I instead Saved the "before" mission and then selected Mission >> Loop it worked as expected
The firmware used in SITL was latest Plane.
Contributor guide
No contributing guide indexed for this repository
Research direction
Reproduce the issue in MAVProxy's Map view by creating an unsaved mission and selecting Mission >> Loop with the right mouse button, then compare it with the saved-mission path. Trace the map mission-loop handling and verify that unsaved waypoints remain present after the command completes.
Written by the indexing model from the issue text.
Assessment
- Tech stack
- python
- Domain
- frontend
- Issue type
- Bug
- Difficulty
- 3/5
- Estimated time
- 1-2 days
- Activity status
- Stale
- Clarity
- Mostly clear
- Newbie friendliness
- 45/100