Question about default source camera and the render camera setting.
- Dominant language
- Python
- Stars
- 1.2k
- Forks
- 80
- PR merge metrics
- No merged PRs in 30d
Description
I noticed that only when source camera following the setting that azimuth=270, elevation=0, the triplane would render the same image as input under input pose.
My question is, when I have a image under pose $T_0$, and I want to render a image under pose $T_1$. How should I adjust the render camera?
I've tried to get the ref_pose $T_2 = T_dT_0^{-1}$ where $T_d$ is the default pose, and convert $T_1$ with ref_pose, but it totally gives an wrong image.
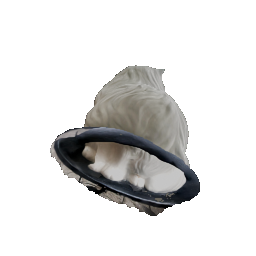
In my setting, the camera distance is 1.5, and the input azimuth is 2.3562(rad), elevation is -0.1317(rad)
the target azimuth is 0, elevation is 0.52359878.
The input image
And the target image
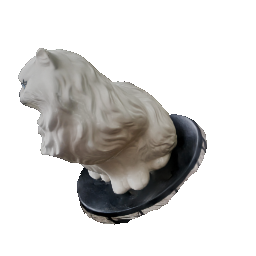
Both two image are rendered by blender.
Contributor guide
No contributing guide indexed for this repository
Research direction
Start by reading the implementation of the source-camera and render-camera settings, then trace how the input and target poses are converted using the stated camera distance and azimuth/elevation values. Reproduce the mismatch with the supplied images and determine the correct pose adjustment; done means the camera relationship is clearly documented and produces the requested target view.
Written by the indexing model from the issue text.
Assessment
- Tech stack
- blender, python
- Domain
- computer-graphics, computer-vision
- Issue type
- Documentation
- Difficulty
- 4/5
- Estimated time
- 3-5 days
- Activity status
- Stale
- Clarity
- Needs clarification
- Newbie friendliness
- 25/100